I fixed some vibrations on the robot, but it still drives weird with the weapon on, so I put together a little test setup to see if it’s actually a battery issue. From left to right, the meters show voltage at the battery terminals (at the cell itself, to avoid connector/wiring losses), voltage at the ESC power pads (to measure connector/wiring losses), and ESC current.
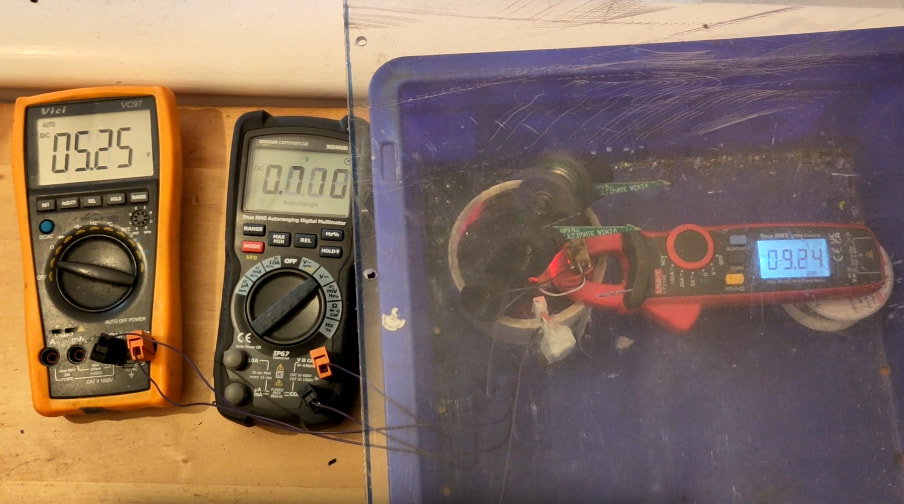
100% power from stopped pulls (very briefly) 9A, and the battery sags to 5.25V. The middle meter thinks the ESC voltage is 0, but I think this is just an auto-ranging issue.
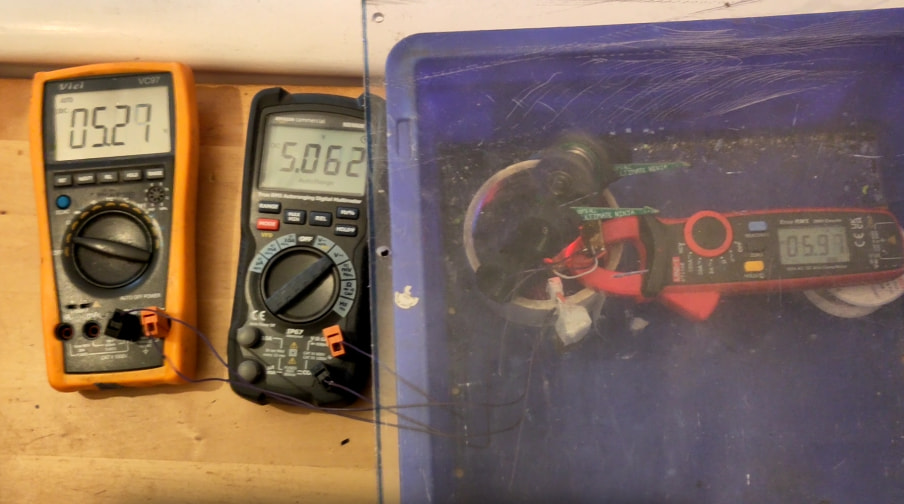
After a few seconds of spinup it hits max RPM, but it’s not happy - I can hear the RPM of the motor fluctuating, and the battery still hasn’t recovered to a sensible voltage.
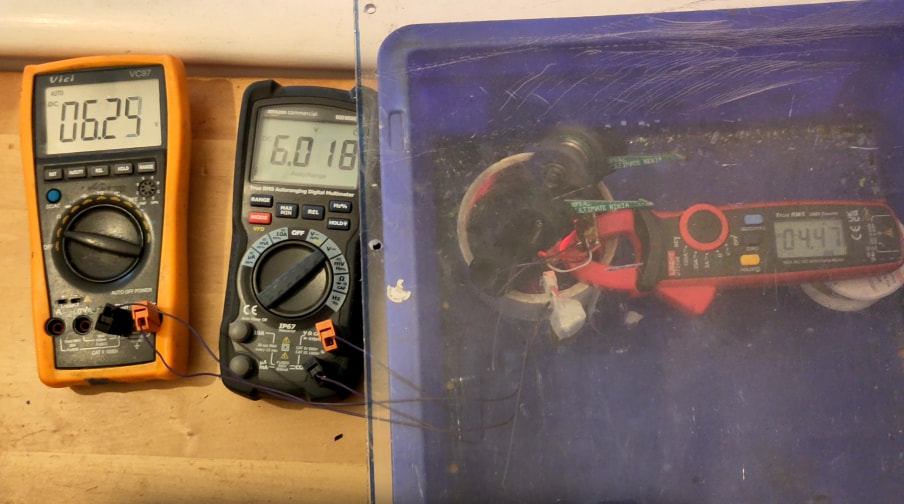
A few more seconds at max speed and things settle down a bit, but the battery still isn’t happy. No wonder it’s getting hot.
So yes, battery issue confirmed. At least there’s only 2-300mV of system voltage drop though, not bad considering it’d the main power connector is rated for 3A and the switch only 1A. Time to go down the antweight battery rabbithole…