Rather than keep making a new topic whenever a brain fart results in a new robot I thought I’d consolidate all my antposting to a single thread. Three of my 150g robots have posts already, I will post future updates here but the existing threads can be can be seen here:
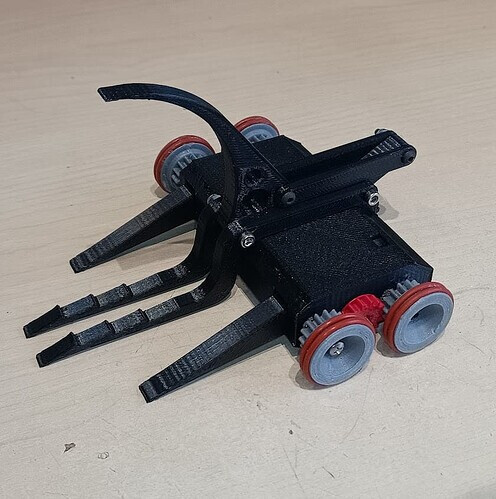
There is one I haven’t posted about much however, and that’s actually my first ant, Fatal Deviant. Initially just a 60% scale version of my first beetleweight, Fatal Deviation for drive tuning, driving practice, and just an excuse to fight more robots tbh.
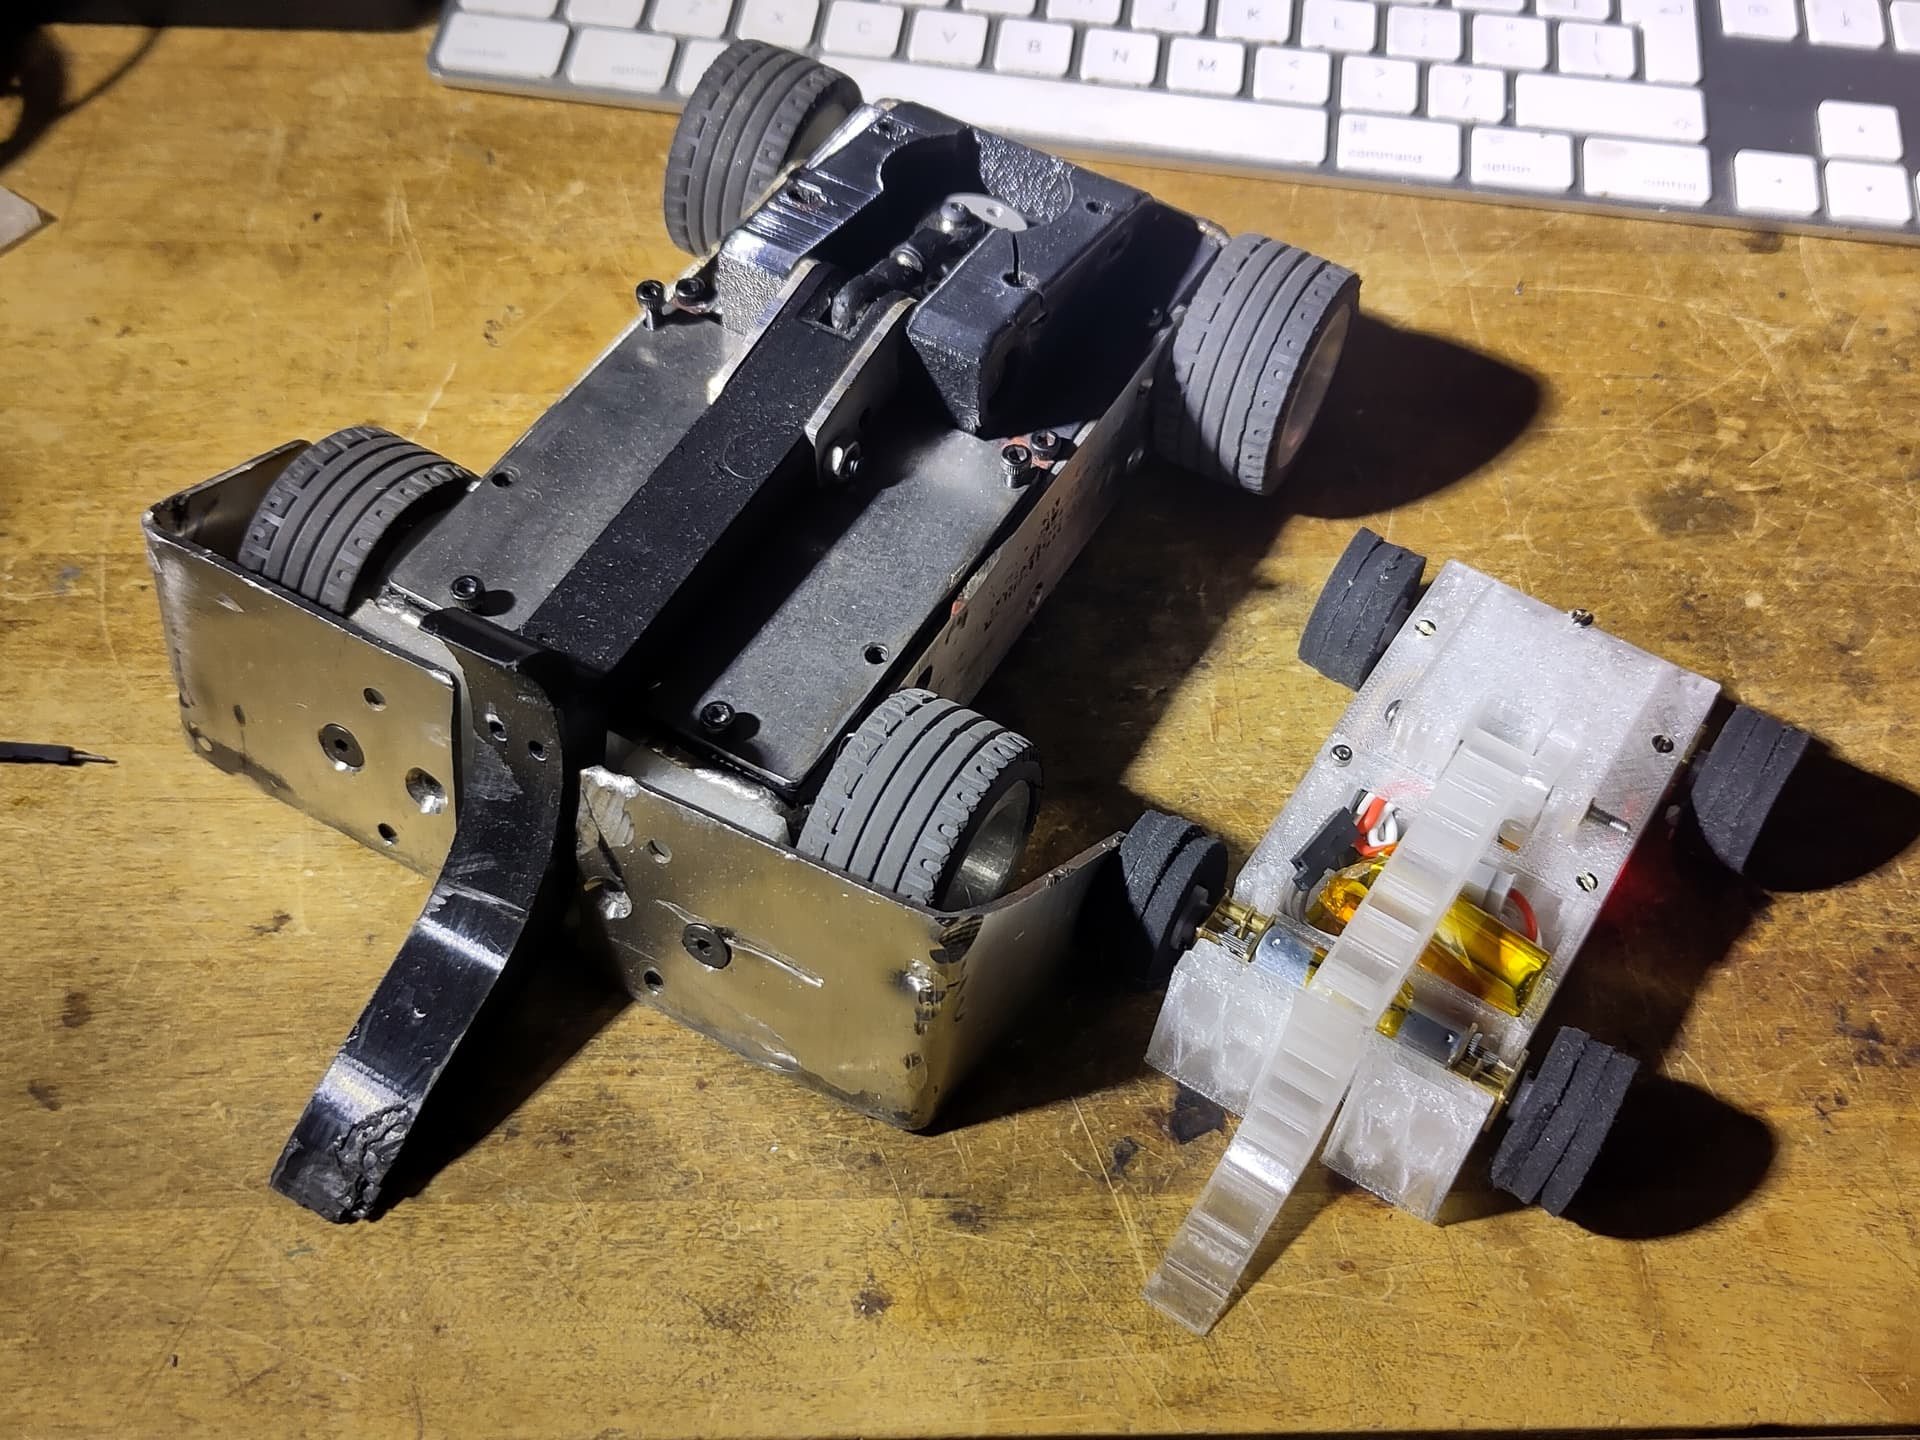
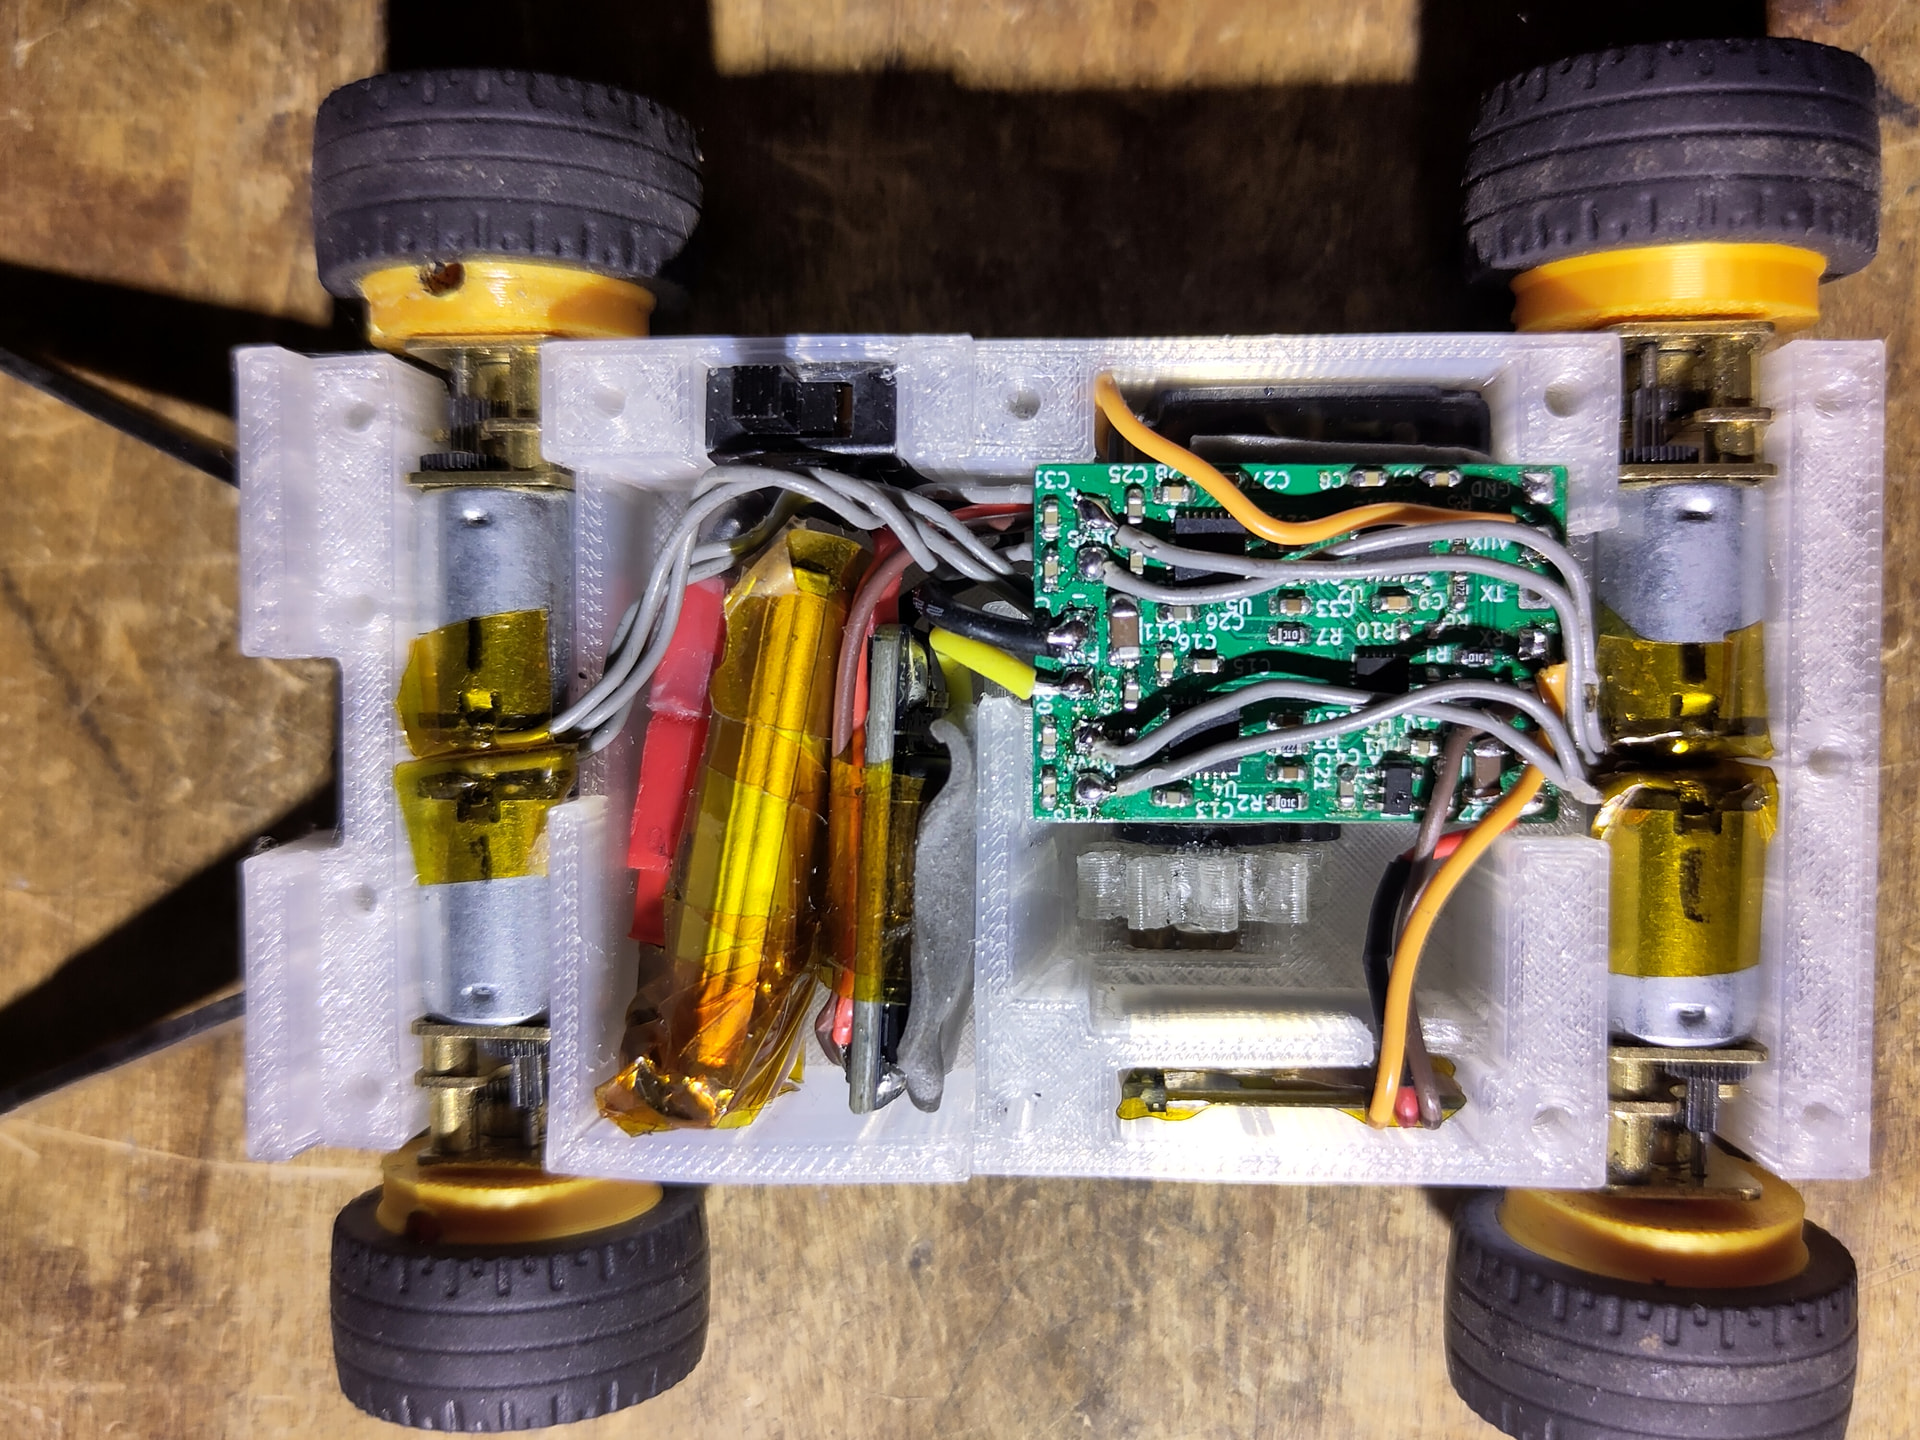
For a lifter bot, a single 280mah lipo cell and a boost converter weighs less than a 3s lipo, with the caveat that you’re limited to about 3A peak and 2A continuous from the boost converter. More than enough for four cheap N20s and a small servo, but not much more.
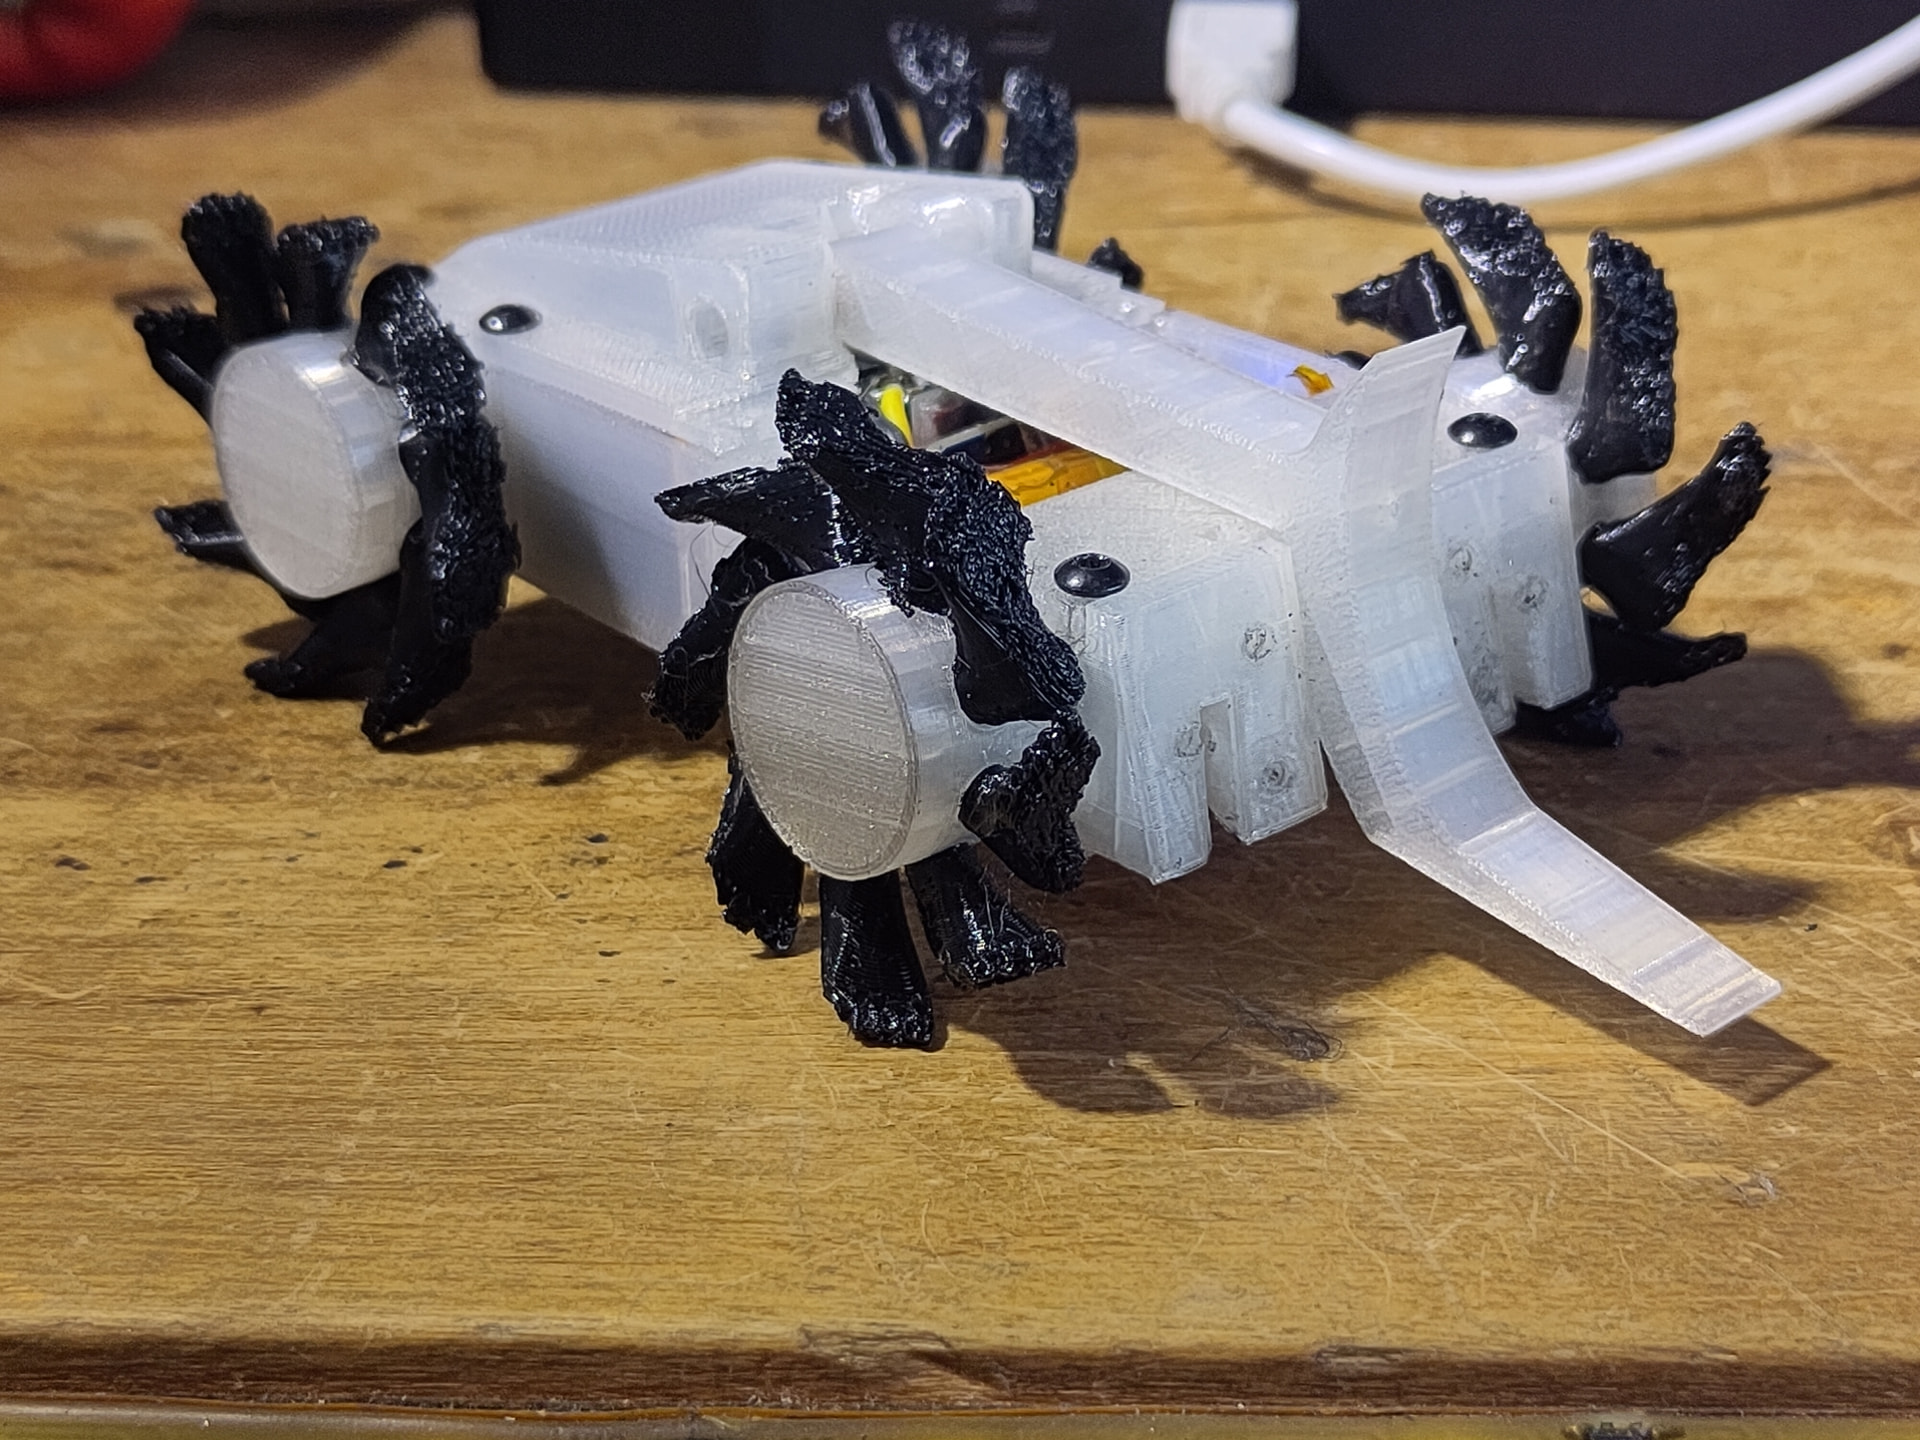
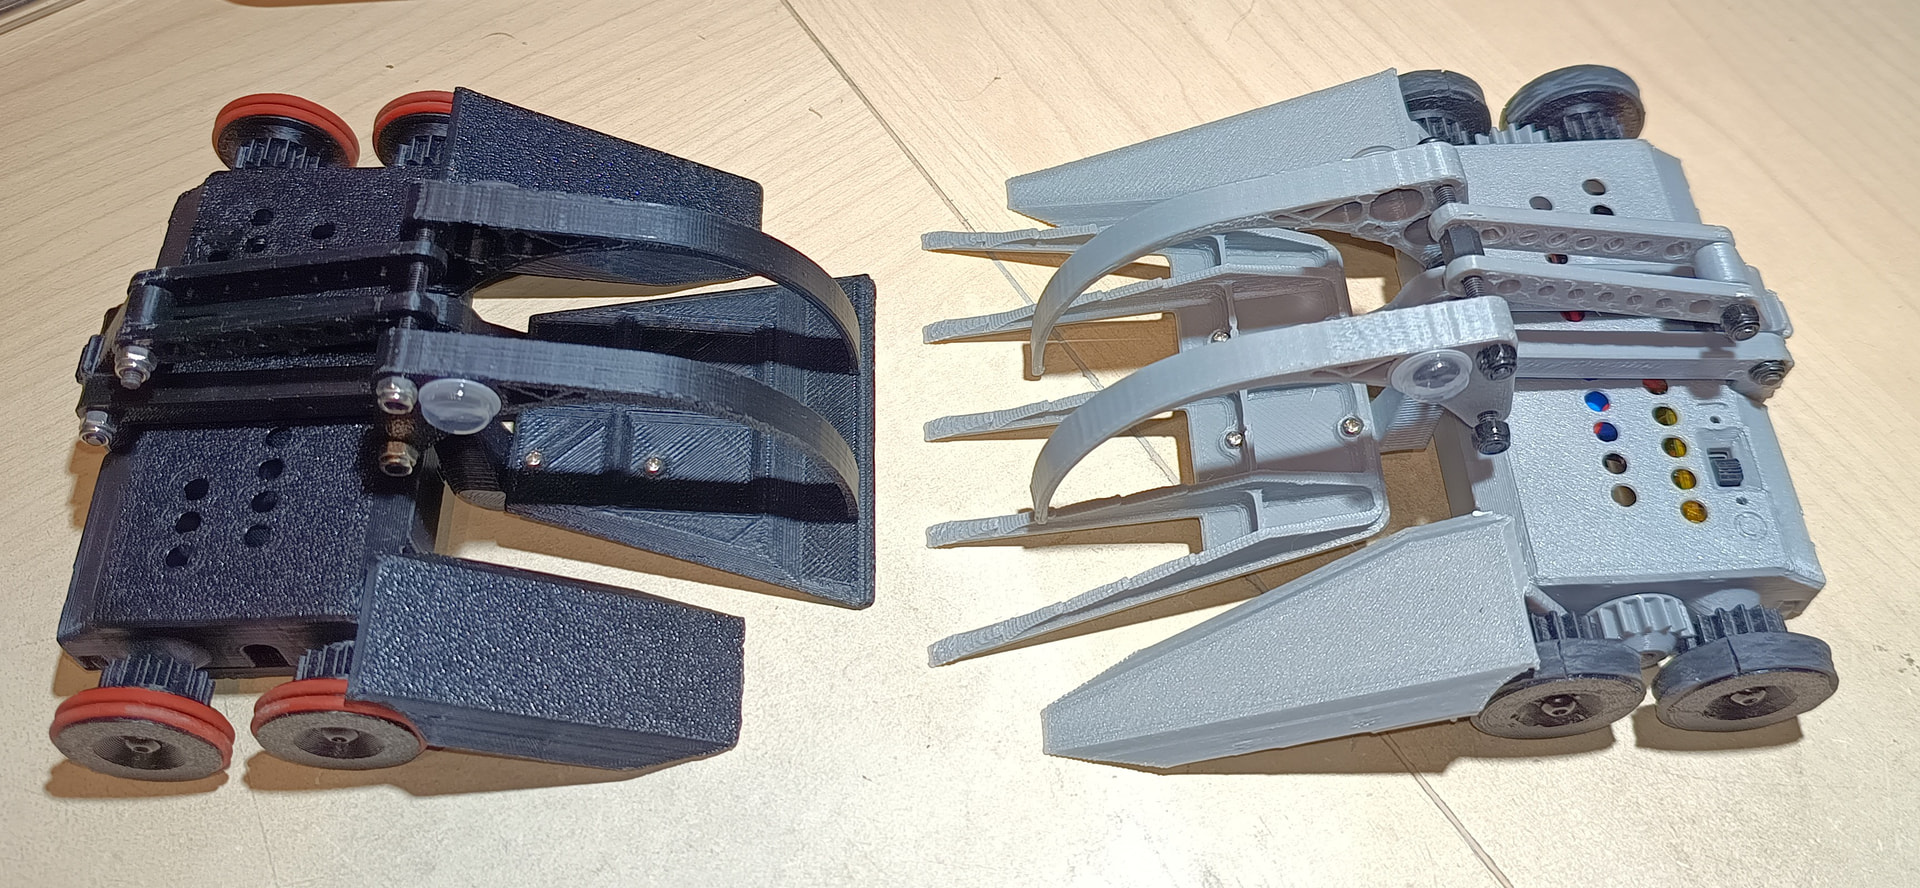
Feetal Deviant, the off-road version for the ORCS warfare arena
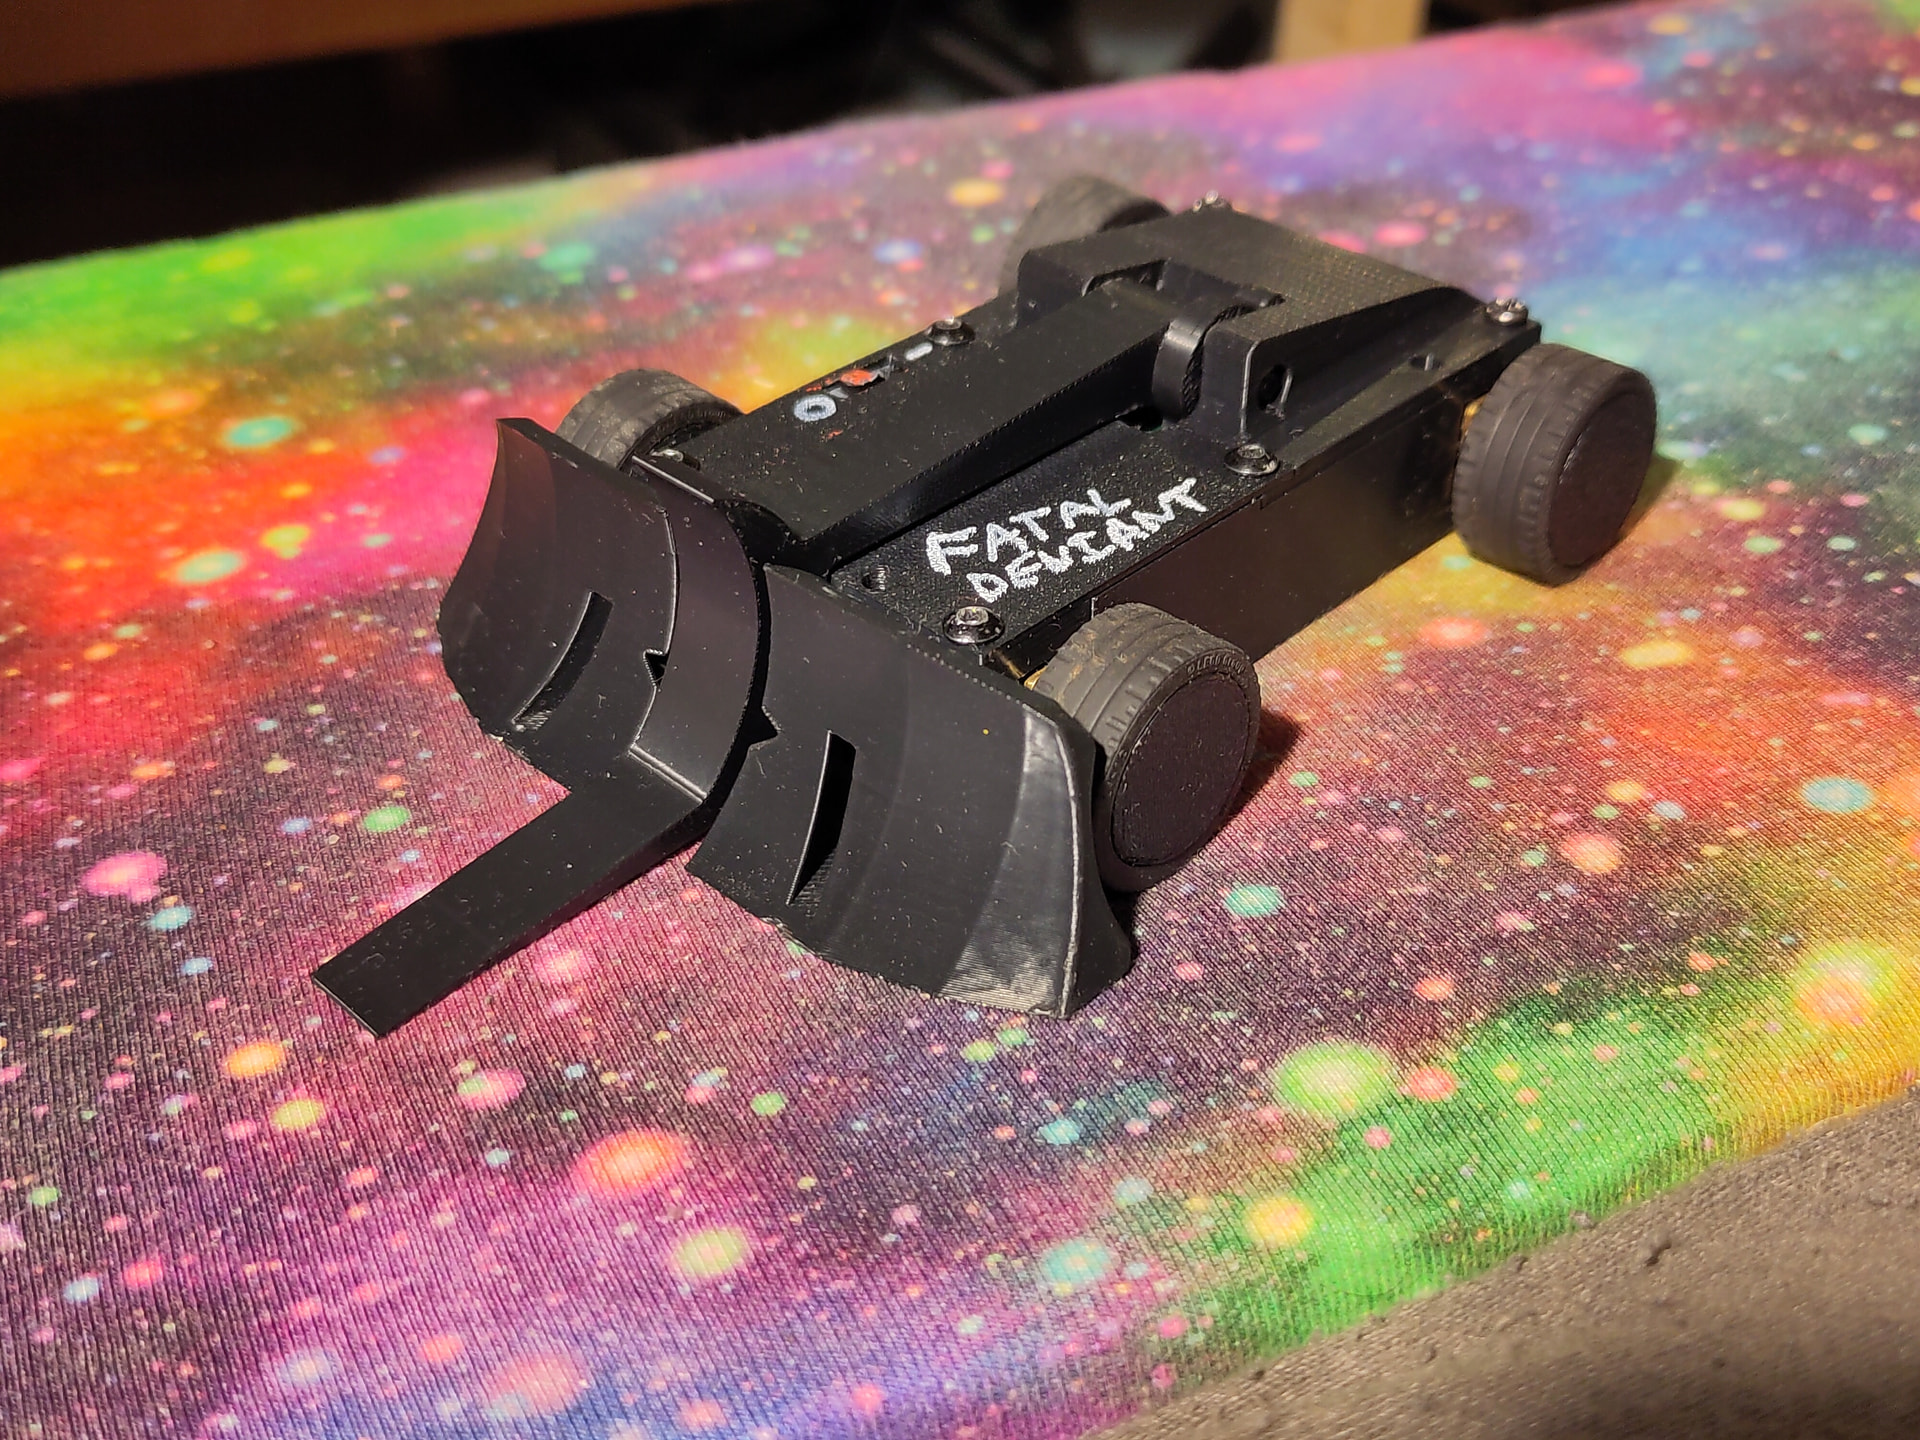
Re-release of the same tired robot but now in a new colourway.
Inside were 4x Aliexpress 1000rpm N20s, a 9g servo, a drive board I slapped together to get a little more value out of a PCB order (otherwise you’re paying £20 shipping for £3 worth of PCBs), a flysky A8S receiver, and eventually a 1s lipo and a boost converter (dialled up to 12V) for ludicrous drive speeds. The weapon was pretty anaemic, but with the same stability control as the full size Fatal Deviation and four high speed N20s running at double their rated voltage it had a top tier box rush:
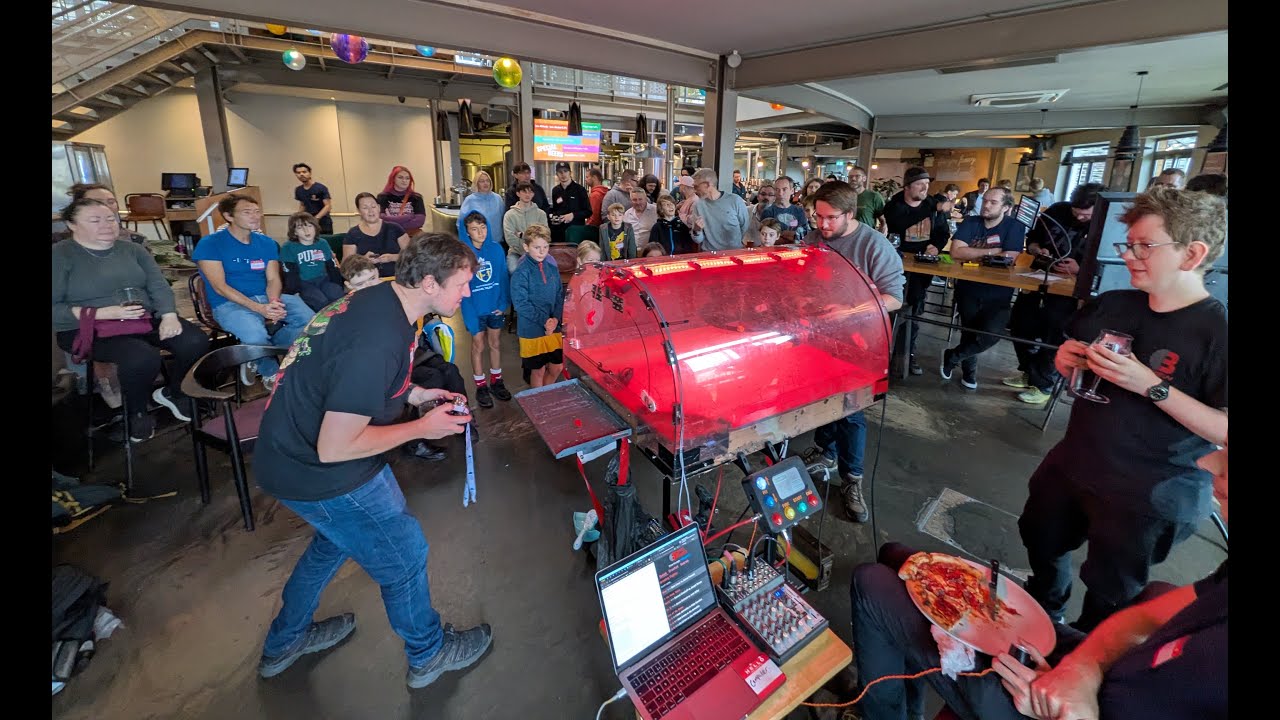
The drive was not just fast but also drifty - having a motor per wheel means that when a wheel breaks traction it’s allowed to spin free, no second wheel attached via belt or gears to slow it down. Unfortunately, good drive was all this iteration of the bot had going for it, and I was soon wishing I had a more powerful weapon. I kept finding myself in position to use the lifter, but then finding the lifter wasn’t actually powerful enough to really do much of anything.
By this point I’d fought Birdemic a few times, and was deep into designing Ultimate Ninja, so fired up FreeCAD (for my sins) and applied some things I’d learned:
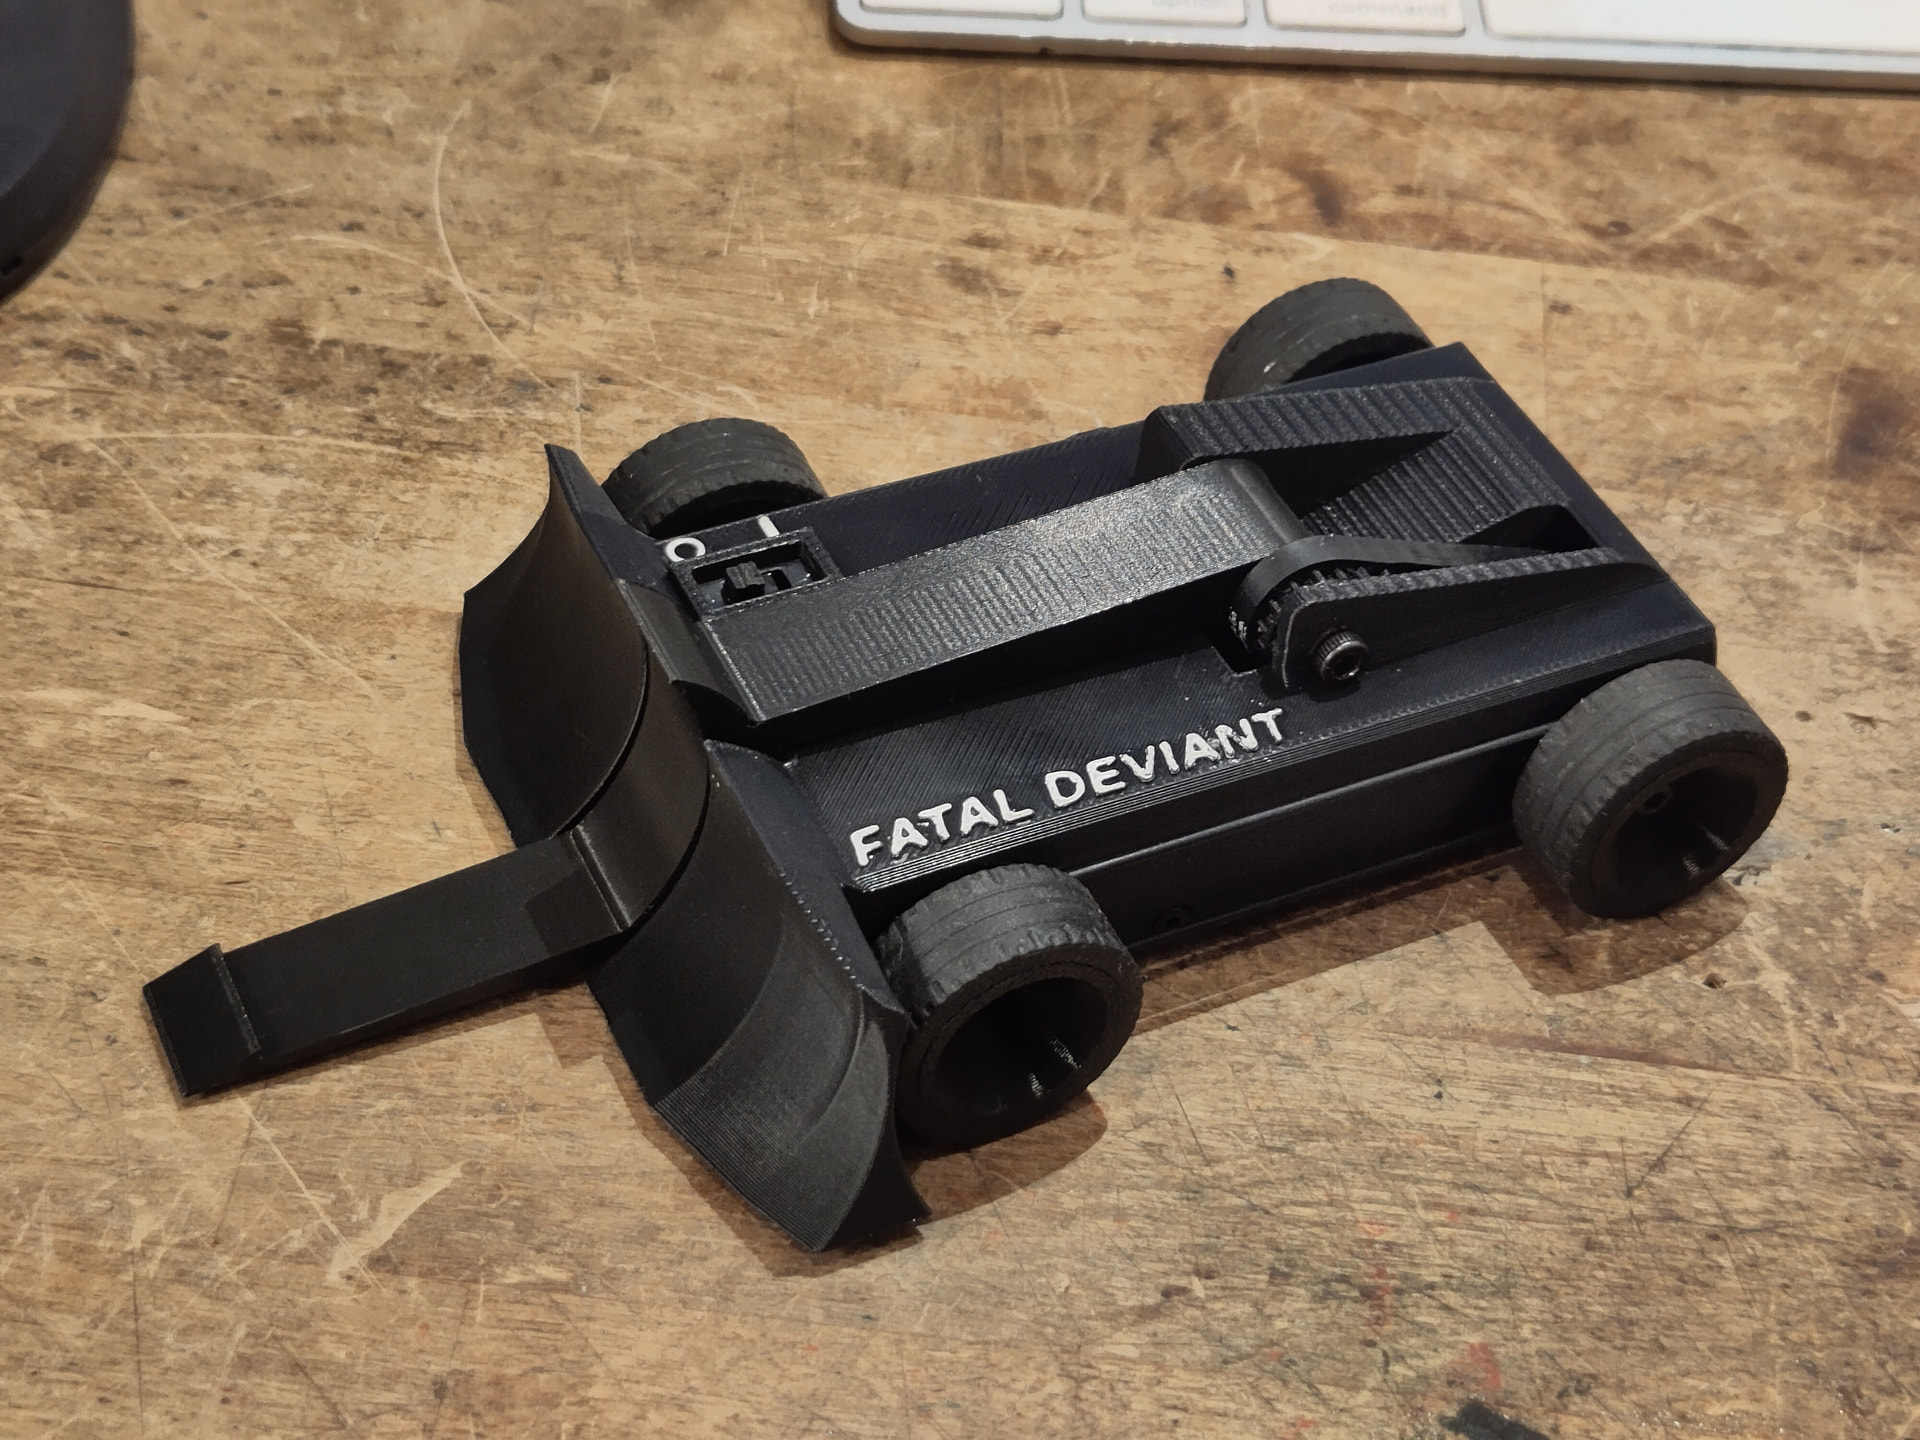
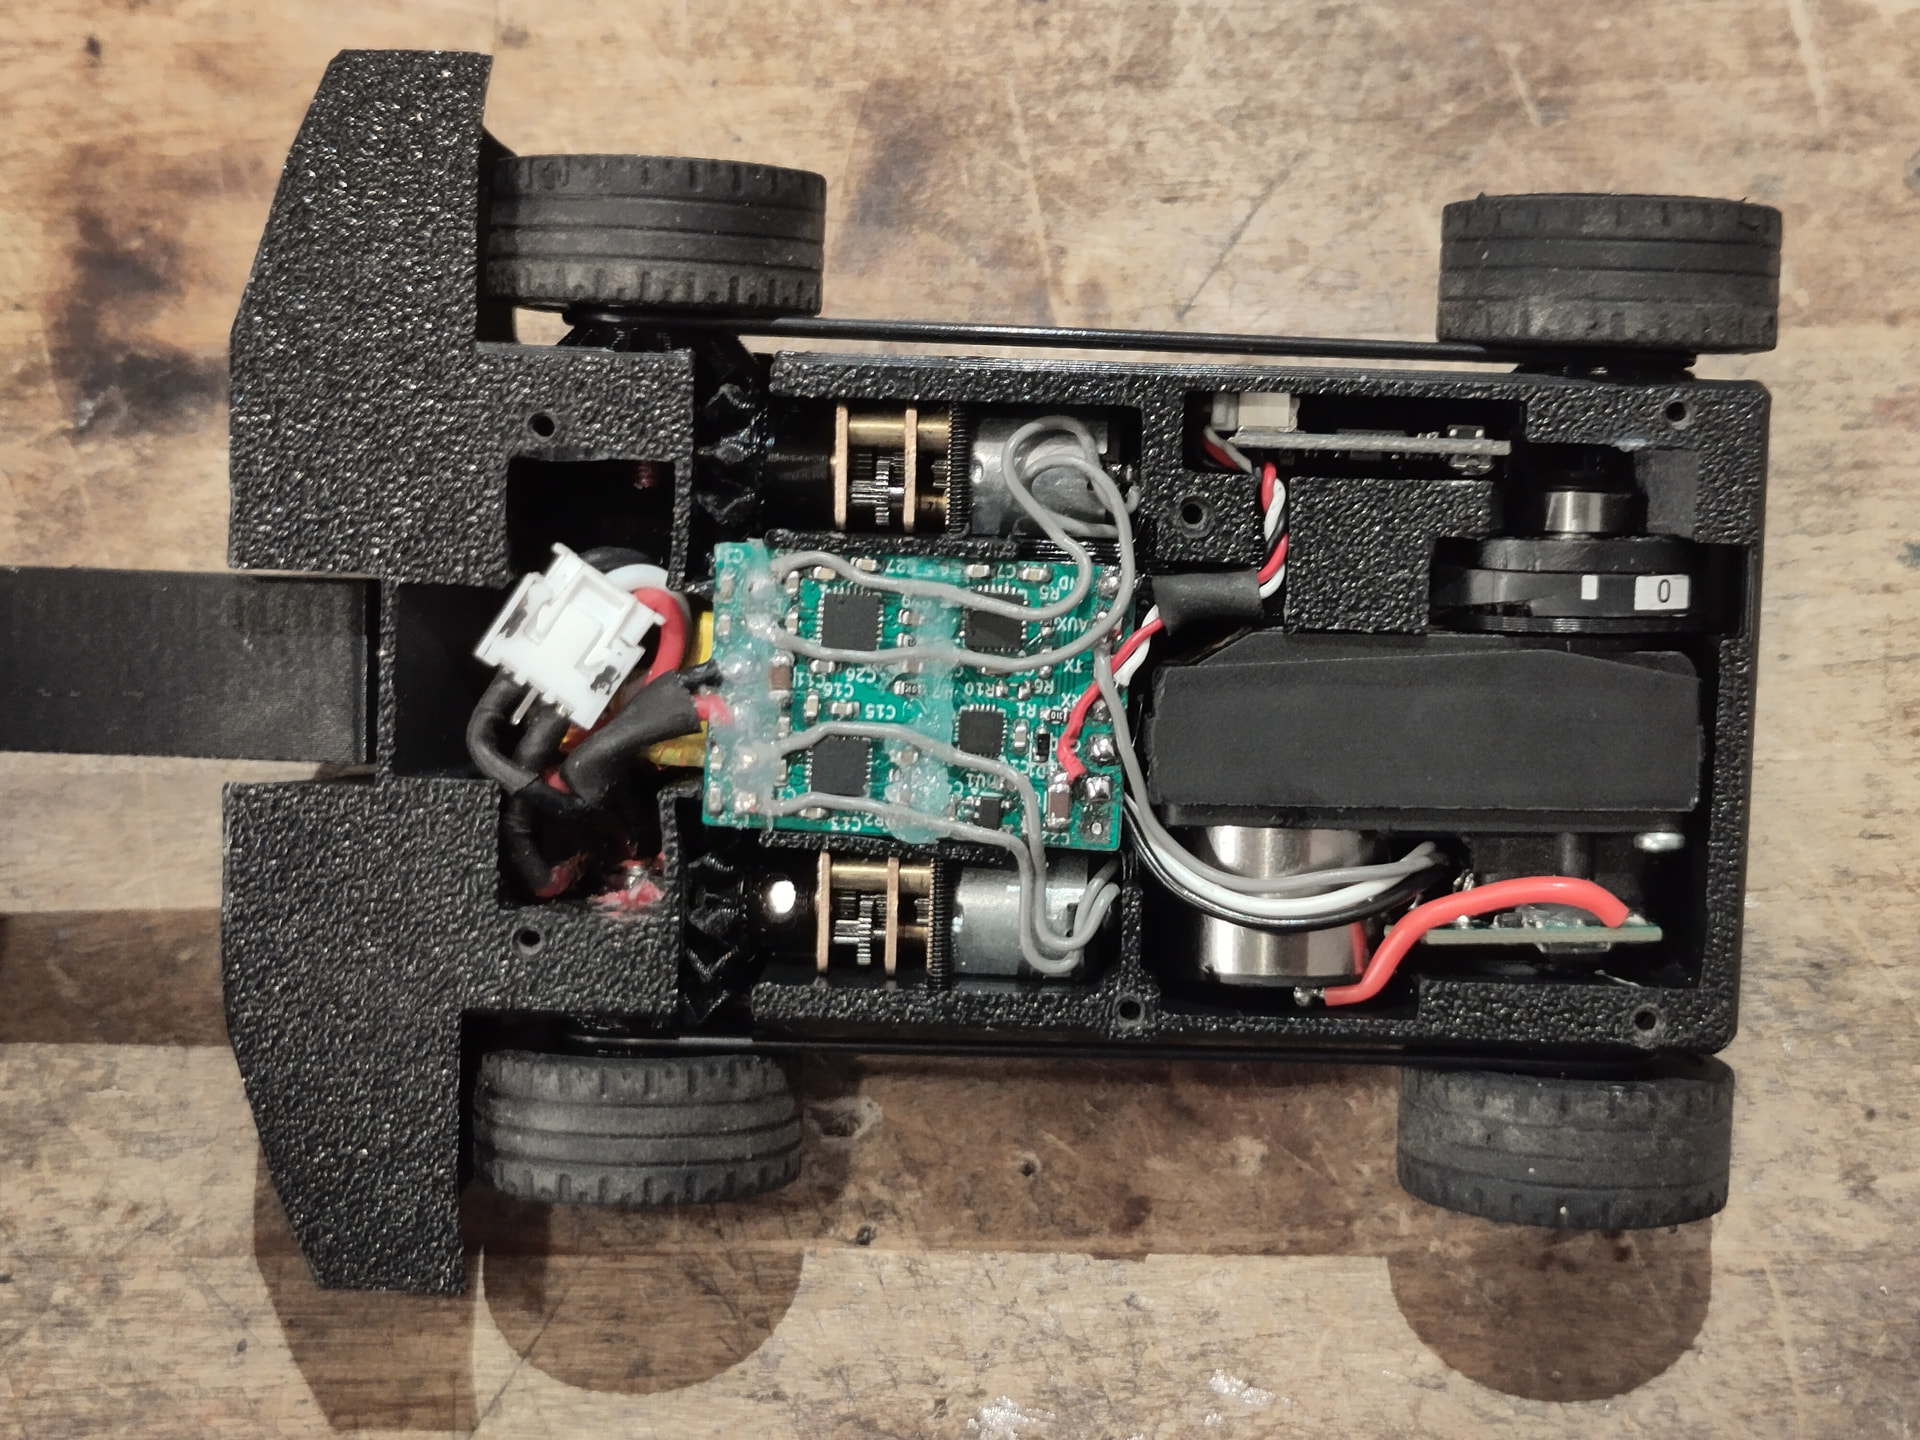
Birdemic showed me I could fit the important parts of a beetleweight servo inside an antweight, so I did the same thing again. This time it was a brushed version, using the standard servo drive board but with a coreless motor from another servo swapped in. The weapon arm was driven via a belt, giving approximately a 1.6:1 overdrive ratio to turn some of the excess torque the servo has into more speed. There was no way the old boost converter setup would work with this servo, so this version used a real 2S battery. To make weight and space for this I swapped from the 4x N20s to 2x BBB N10s, and the same bevel drive as Birdemic and Ultimate Ninja - now the same wheels and pinion gears shared between all three.
Its first outing was GROCS January, where it performed pretty well. The 2S drive felt sluggish after driving the zippy little 3S machine that is Birdemic, but the flipper worked pretty well. It’s absolutely my favourite robot to drive during a rumble. I just drive around and if a robot is on the flipper tongue I press the button and they go flying, sometimes straight out of the arena. Robot on the weapon? Flip’ em. Two robots grappling? Flip 'em. Three robots grappling? Sure, I’ll flip 'em too:

I drove it like this for a bit. At some point I switched to a 180mAh 3s lipo (made from 3x 1s drone cells soldered together) and the servo started freaking out and vibrating violently at certain positions and loads (some of those loads being “idle”). I had to add 3x diodes on the servo’s voltage line to drop the voltage a little so that it would be happy, so flips got better but there was still some power left on the table. It drove much faster on 3s, but still a bit wonky - the weight bias was towards the rear, and combined with the long wheelbase it was kind of unwieldy to drive.
After burning out 3x N10 motors in three fights at the BBB June ant social, then again another one while driving in my sportsman arena at another event, I was pretty done with this iteration costing me £20 in motors for about five minutes arena time. So obviously rather than troubleshoot it I went tangent drive instead.
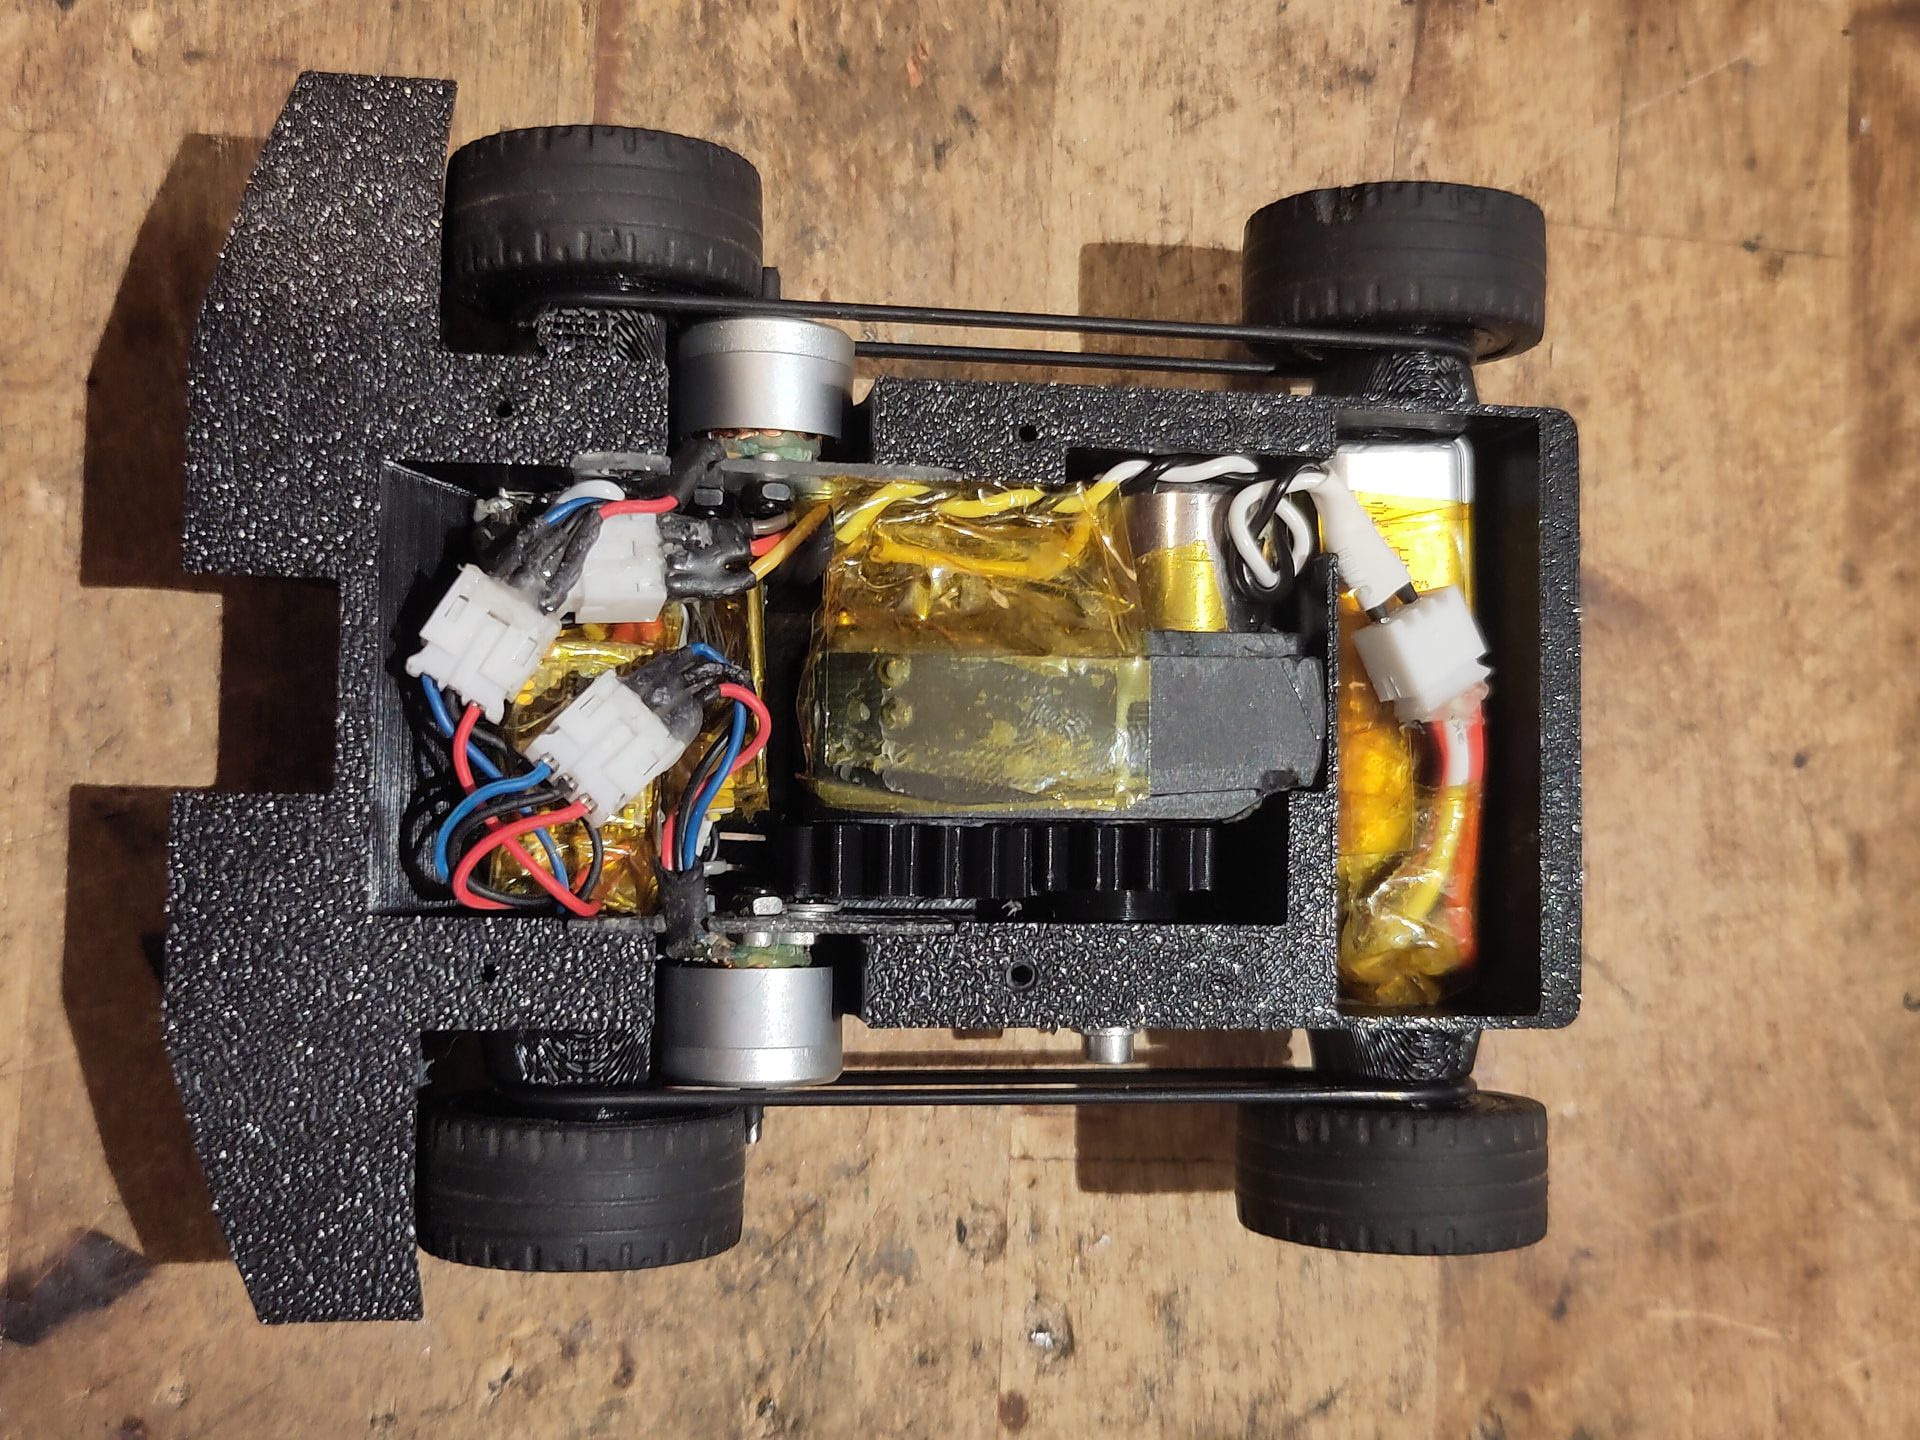
Back to 2s - perfect top speed with these 4300kv 1104s. Unfortunately the BLHeli_S firmware that comes on most small ESCs just isn’t up to low speed control, and there were multiple instances where I told the bot to drive straight, one motor started and one didn’t, and it turned 90 degrees and then drove straight into the pit. A shame, because it drove really well at higher speeds when the shafts still had their heatshrink on them. I also experimented with a gear-driven weapon instead of a belt, but it was heavier than a belt and still skipped.
It’s a shame tangent drive didn’t work, but I’ve since found some AM32 ESCs small enough to fit inside an antweight, so I might revisit the concept in future.
For the debut ARCS event I did yet another redesign, unfortunately it’s looking a little sorry for itself right now.
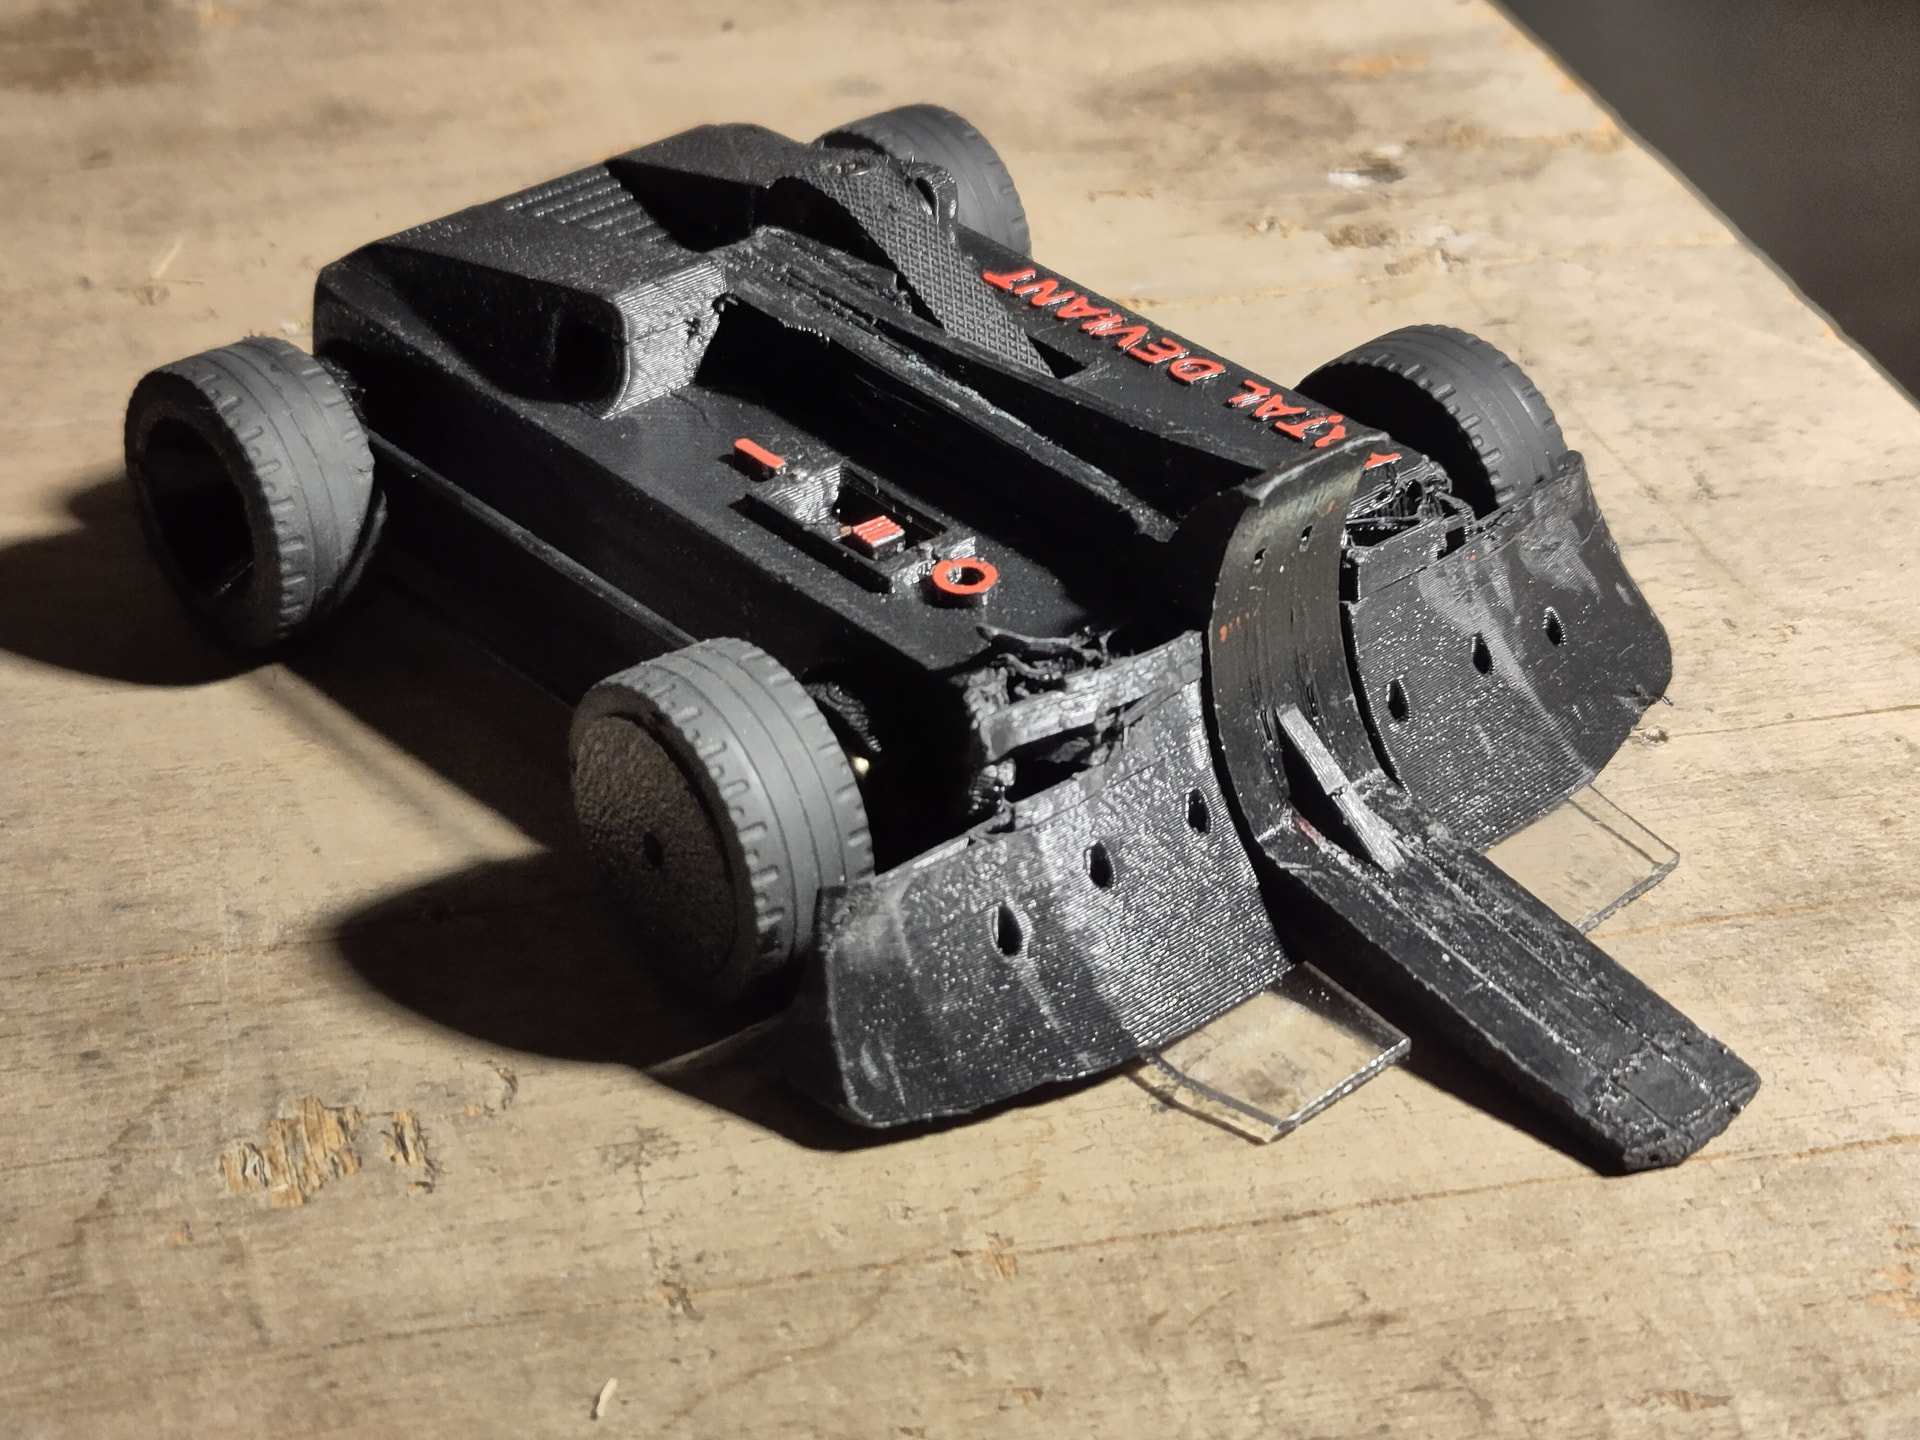
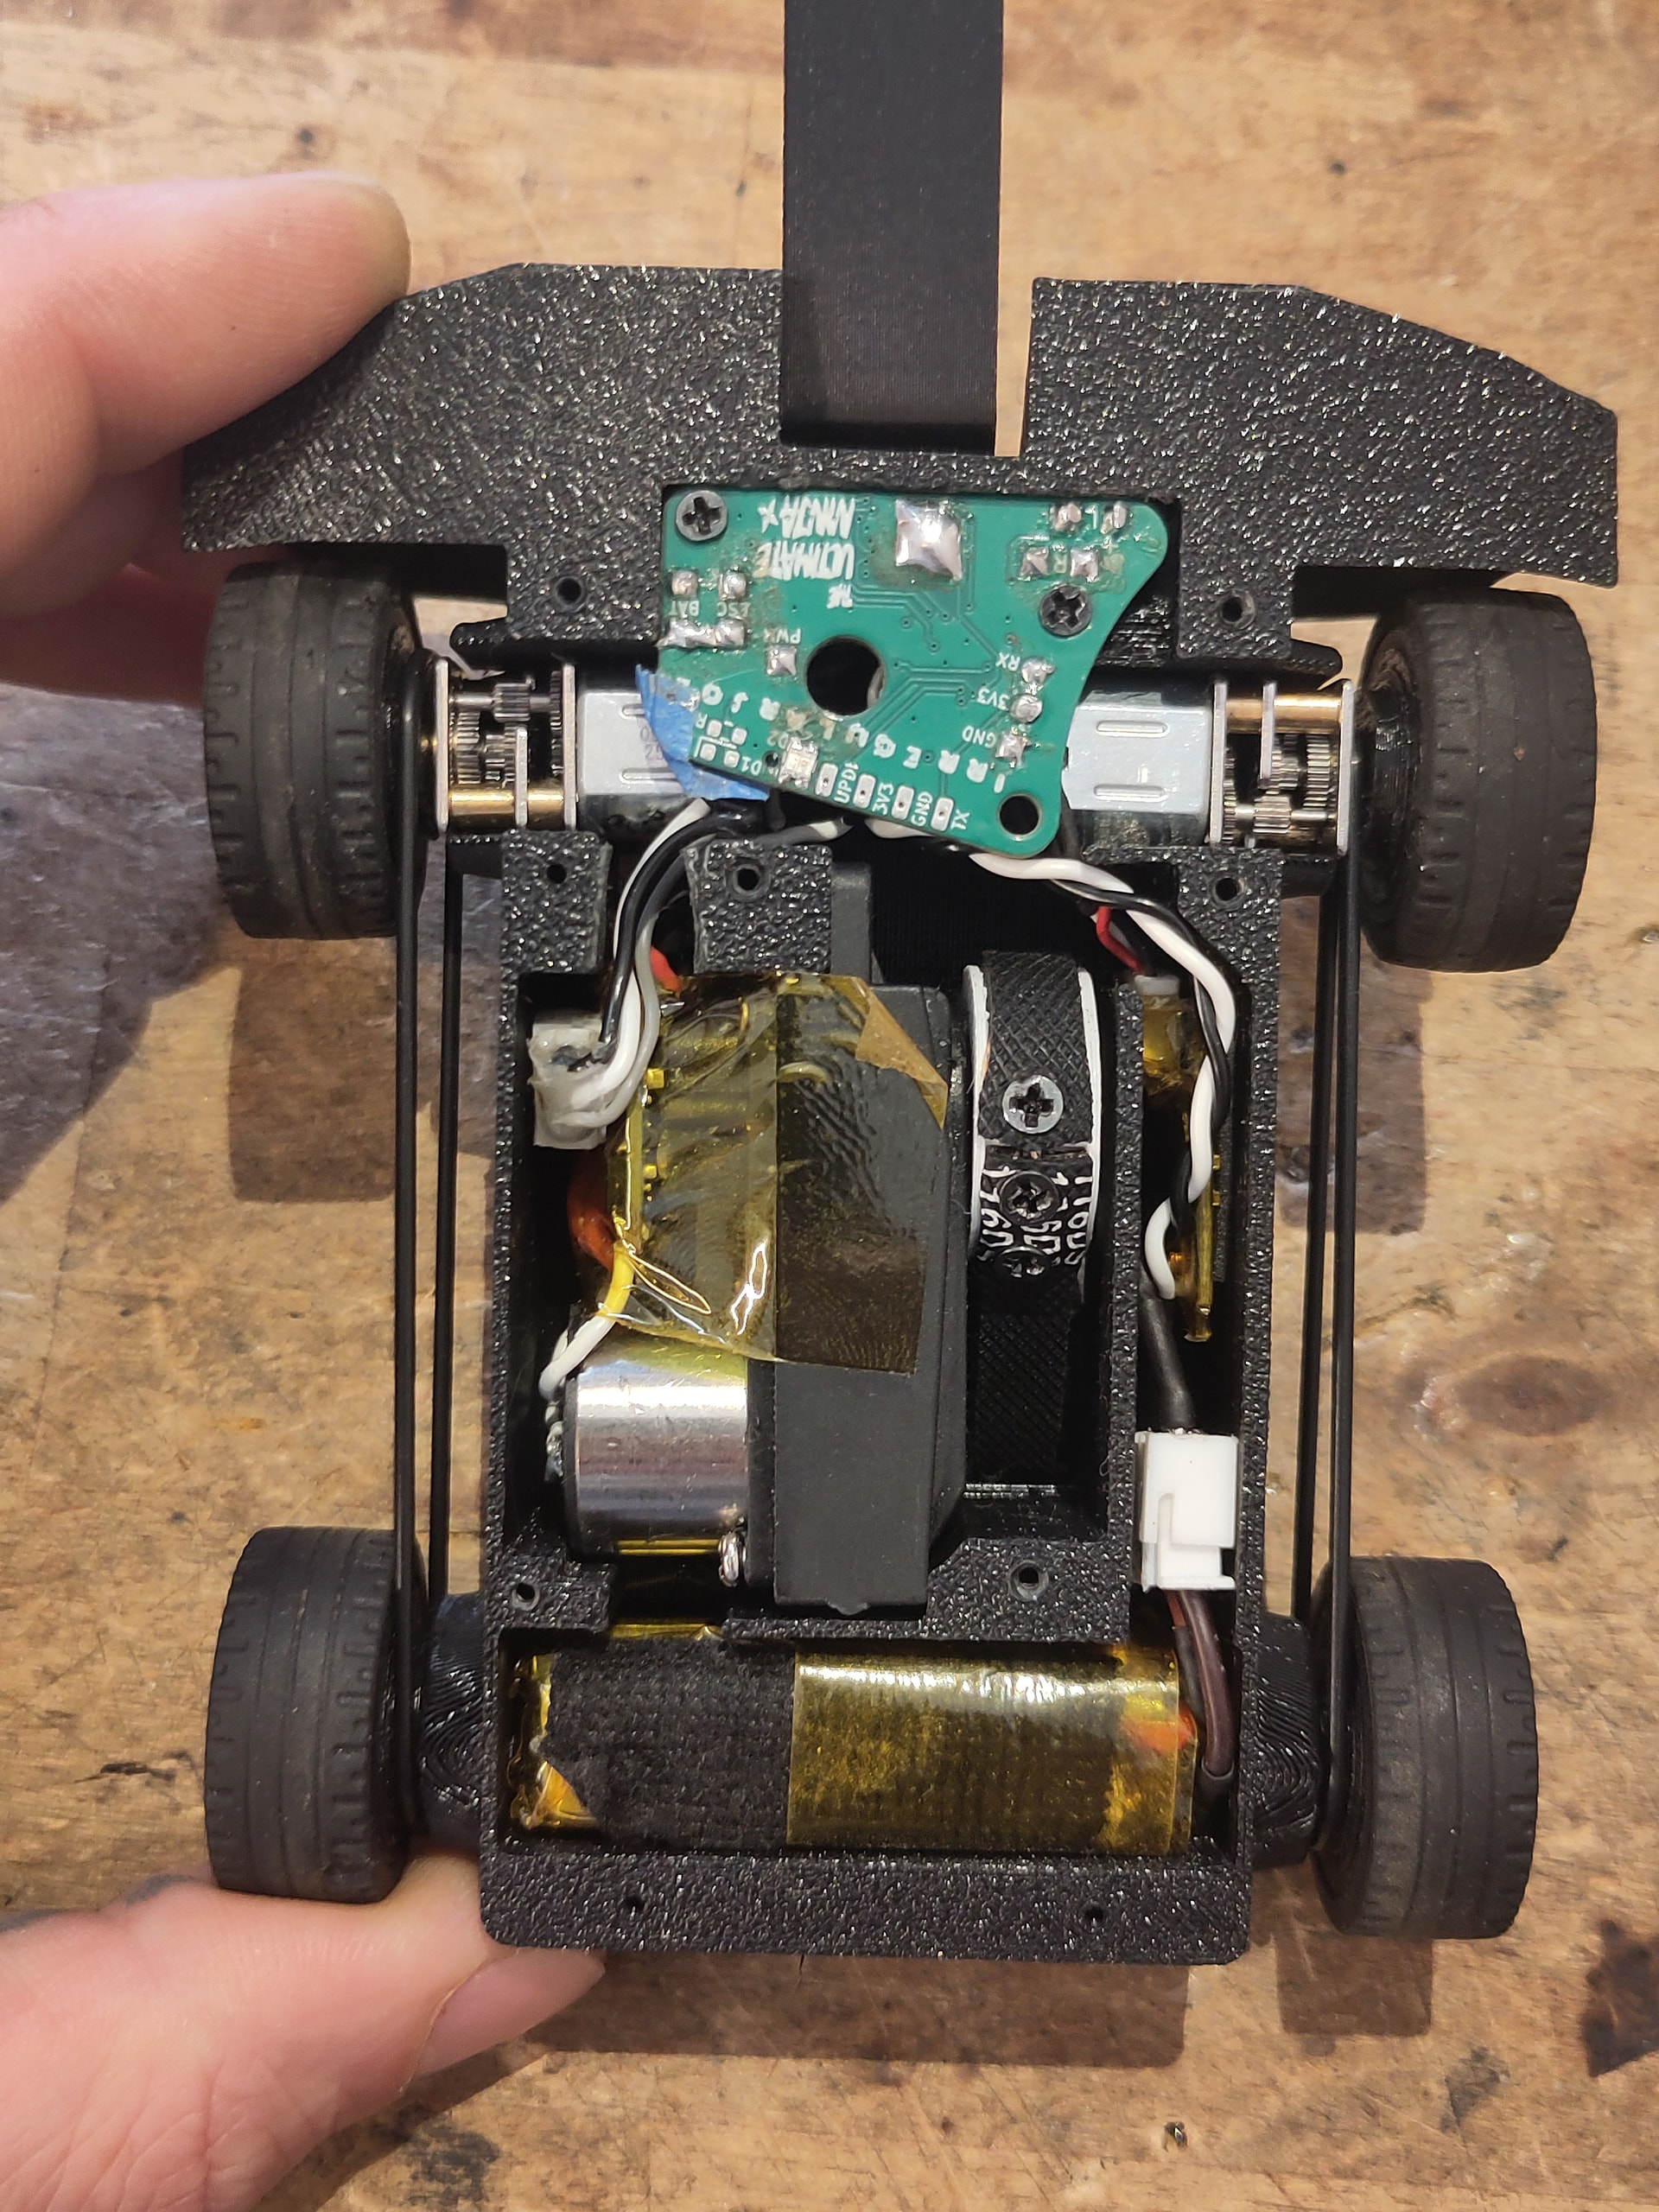
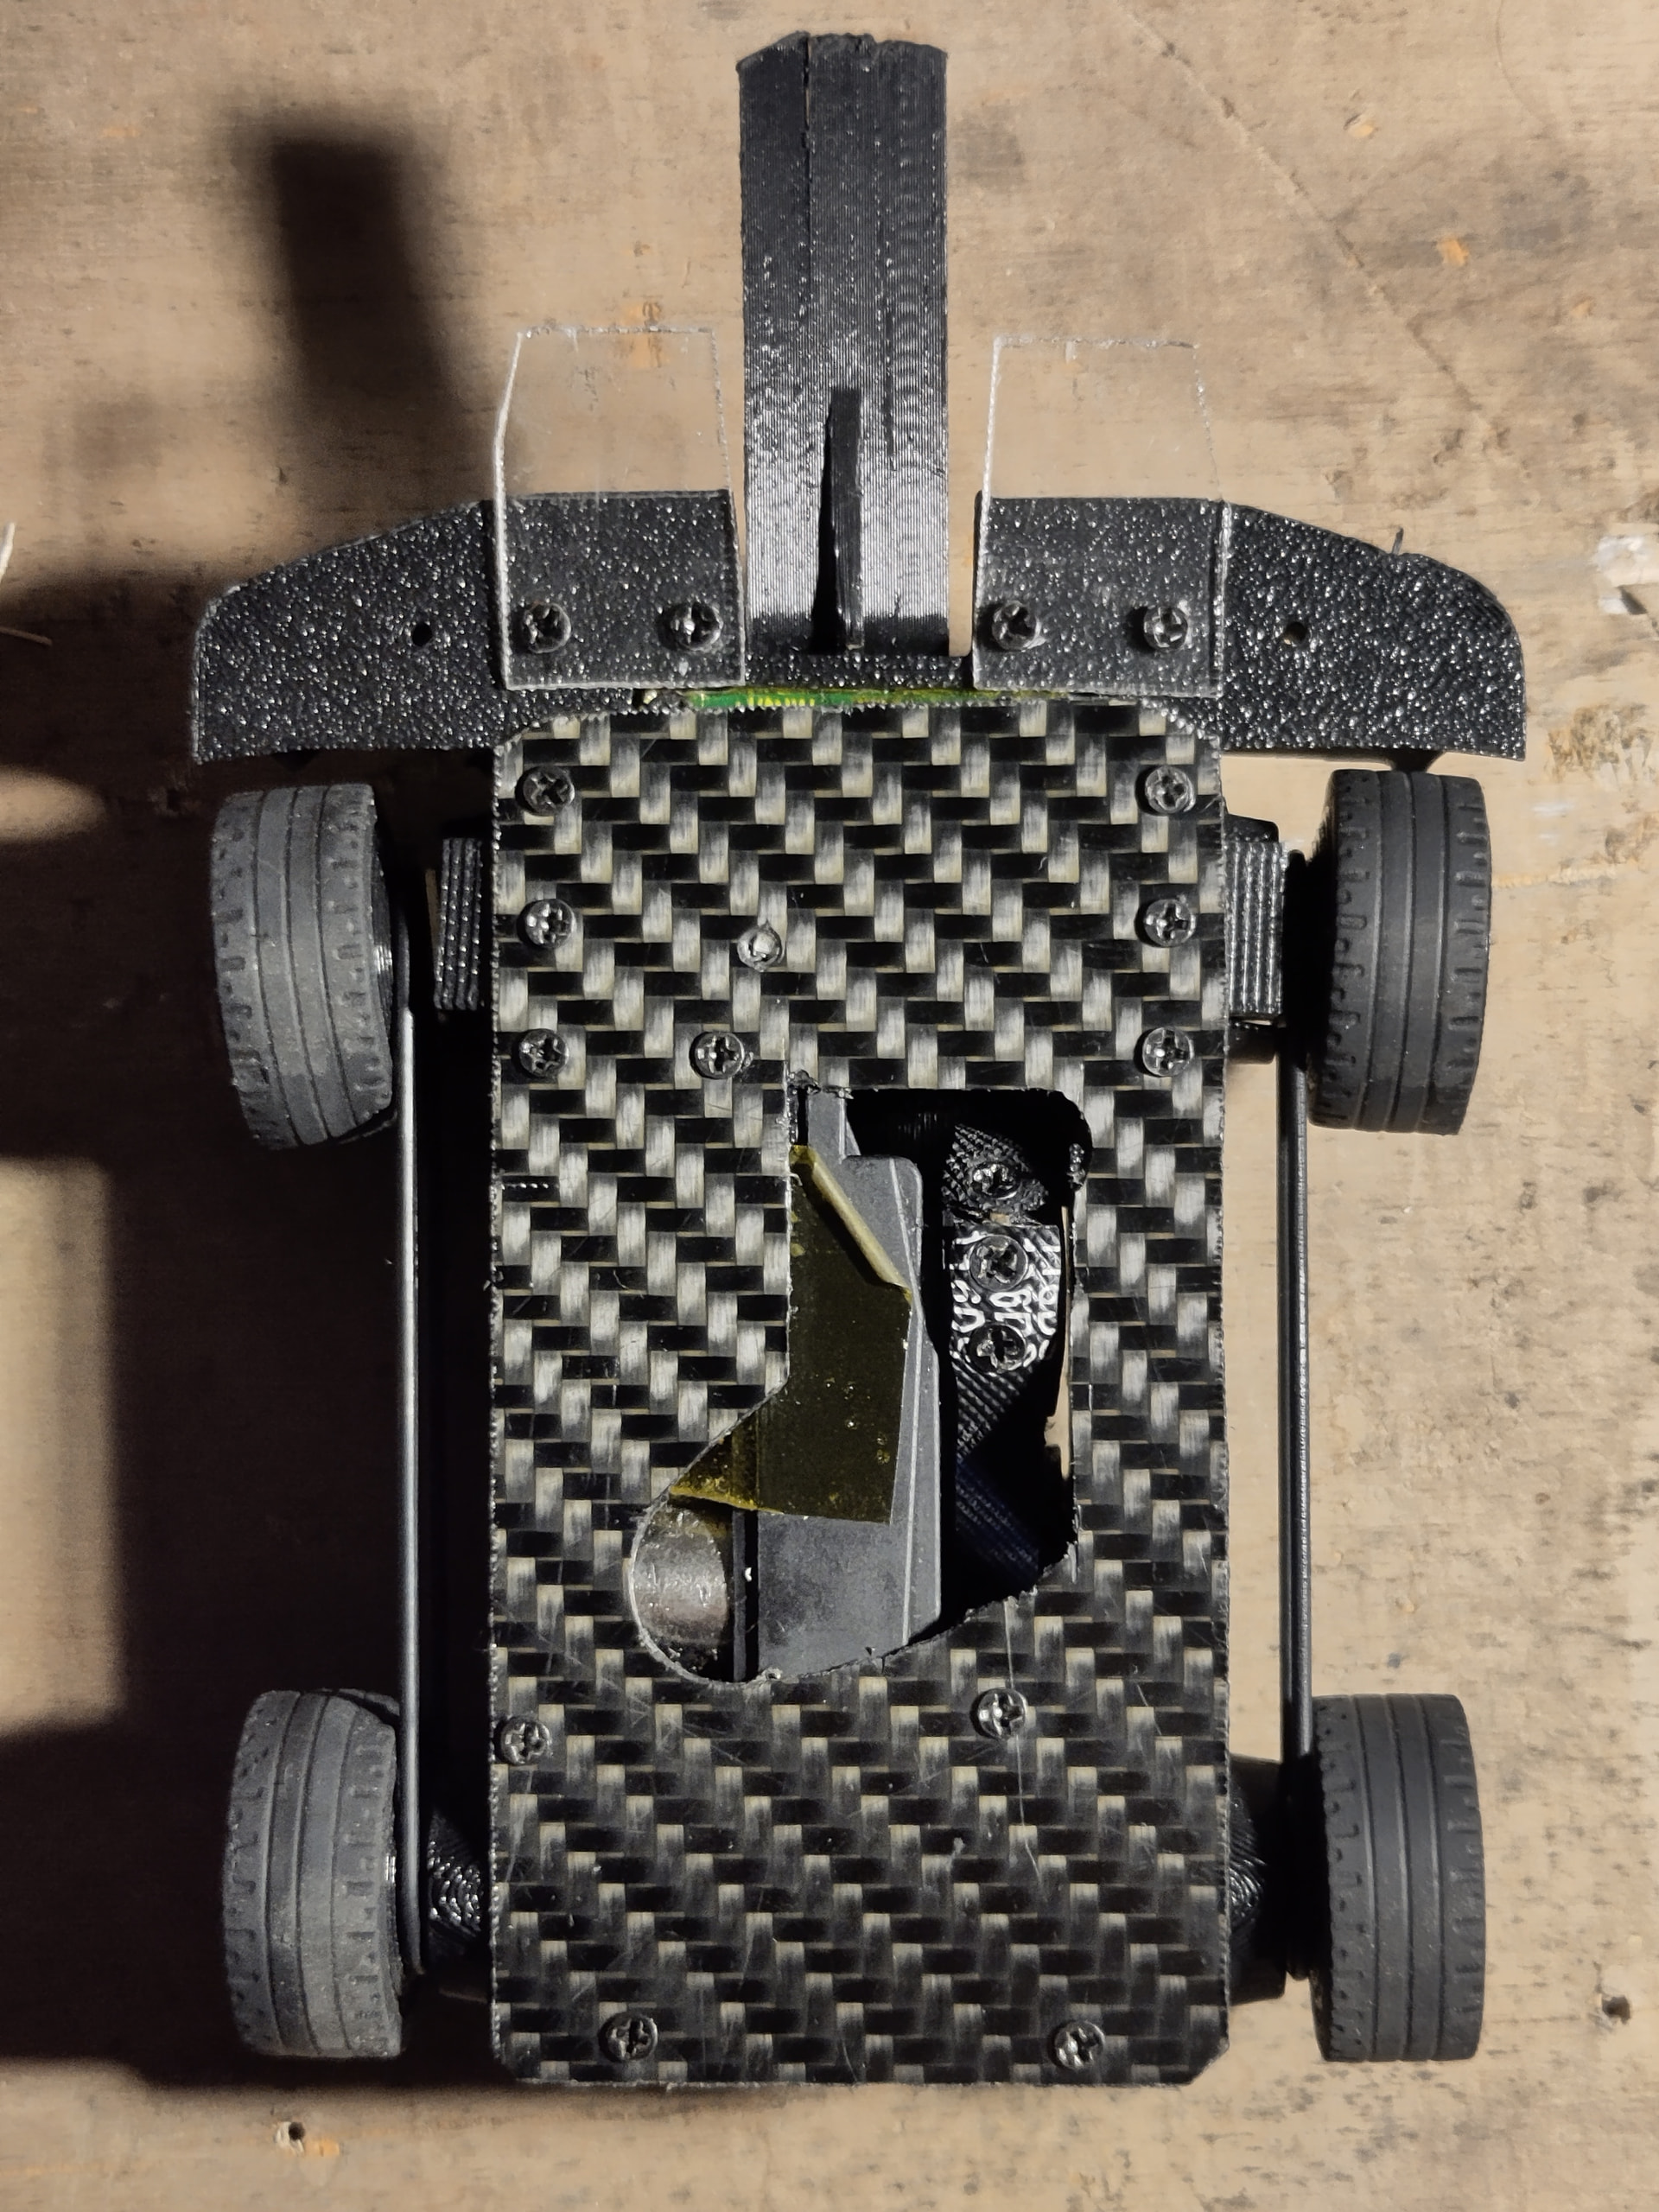
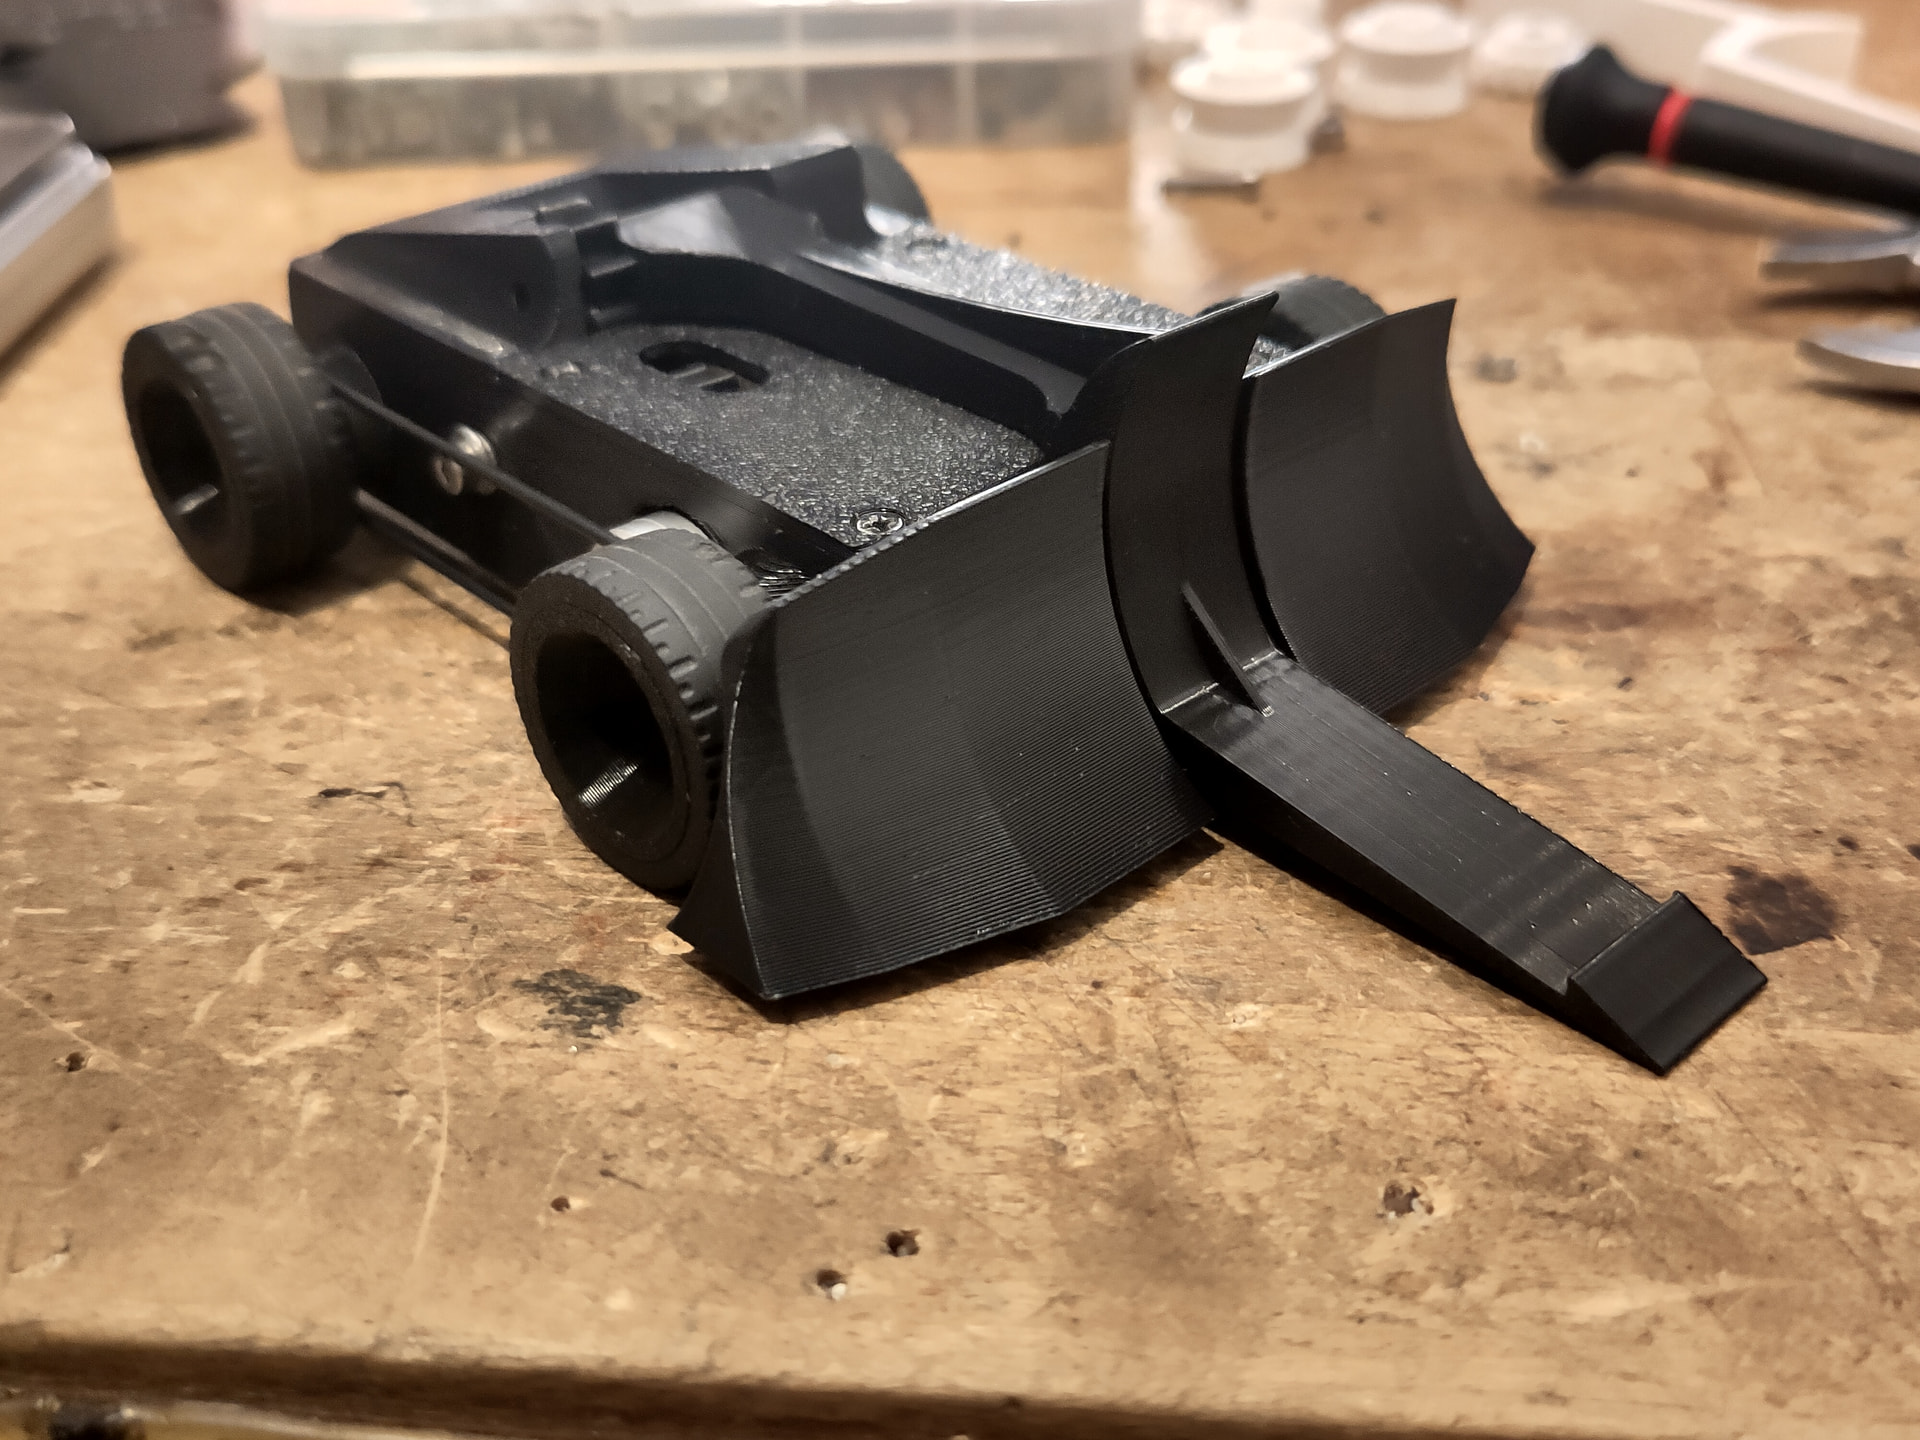
Like every iteration so far it’s a little shorter and a little wider. Back to direct drive, this time with 2x Turnabot N10s. Also back to 3s, and this time straight to the (different) servo PCB that’s perfectly happy at 3s. Bigger weapon belt, which is screwed into the pulley at both ends to finally solve the belt slipping issue. (Bonus, I no longer need to use specific length belts, I can just cut a length off a longer one and screw it into the robot). Now using a spare Ultimate Ninja PCB, since it’s much smaller and lighter than the old one I was using and also means I now have underglow!
The little polycarbonate dingii sticking out the front are stabilising forks, they aren’t actually for ground game. When the flipper fires the rear of the bot has a tendency to lift, to the point that some flips had the robot doing a frontflip. With the polycarbonate tongues there’s a contact point on the front of the bot that’s closer to the tip of the lifter, which reduces this tendency and both keeps my bot more stable and also sends more energy into the opponent.
Best fight of the day for me at ARCS was this one where I manage to pull off the 2V1 win:
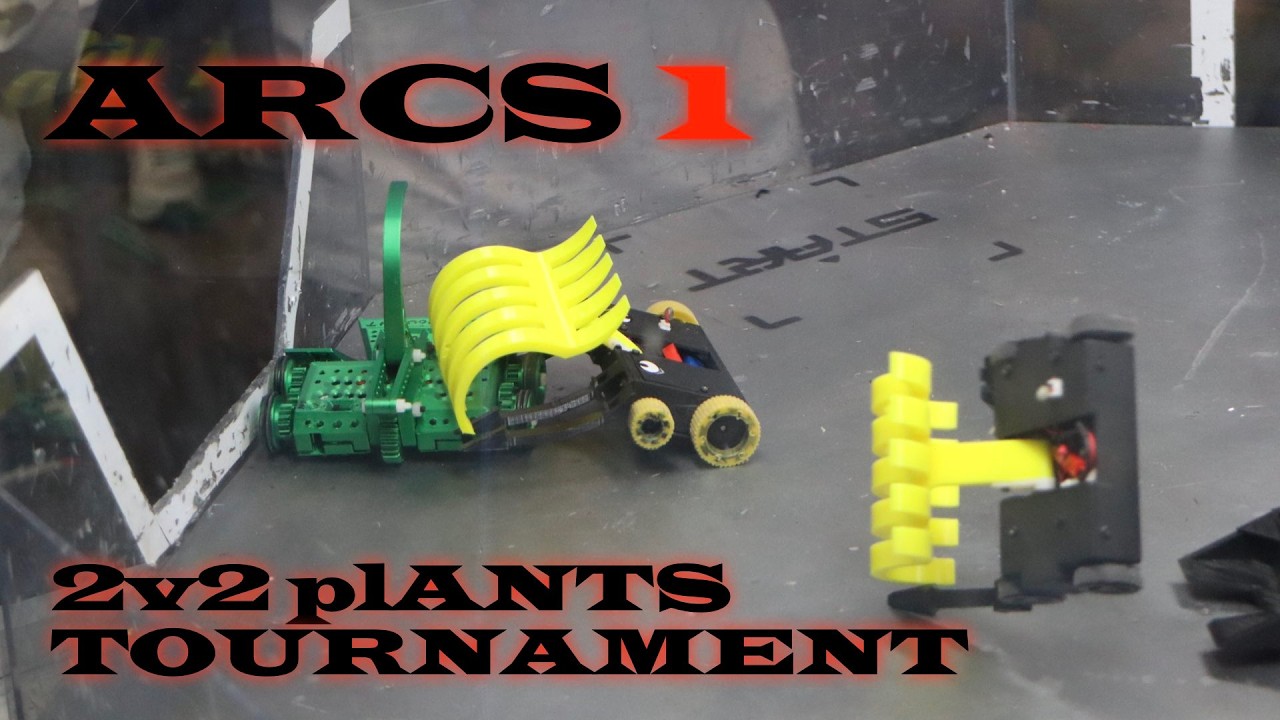
Finally, this iteration drives the way I want it to. It’s also capable of big, repeatable flips, half way to the roof or across the arena, all day long. The servo doesn’t get hot, the belt doesn’t skip, it just flips stuff good. If you ever lose sight of it in a rumble, just look for the flying robots:
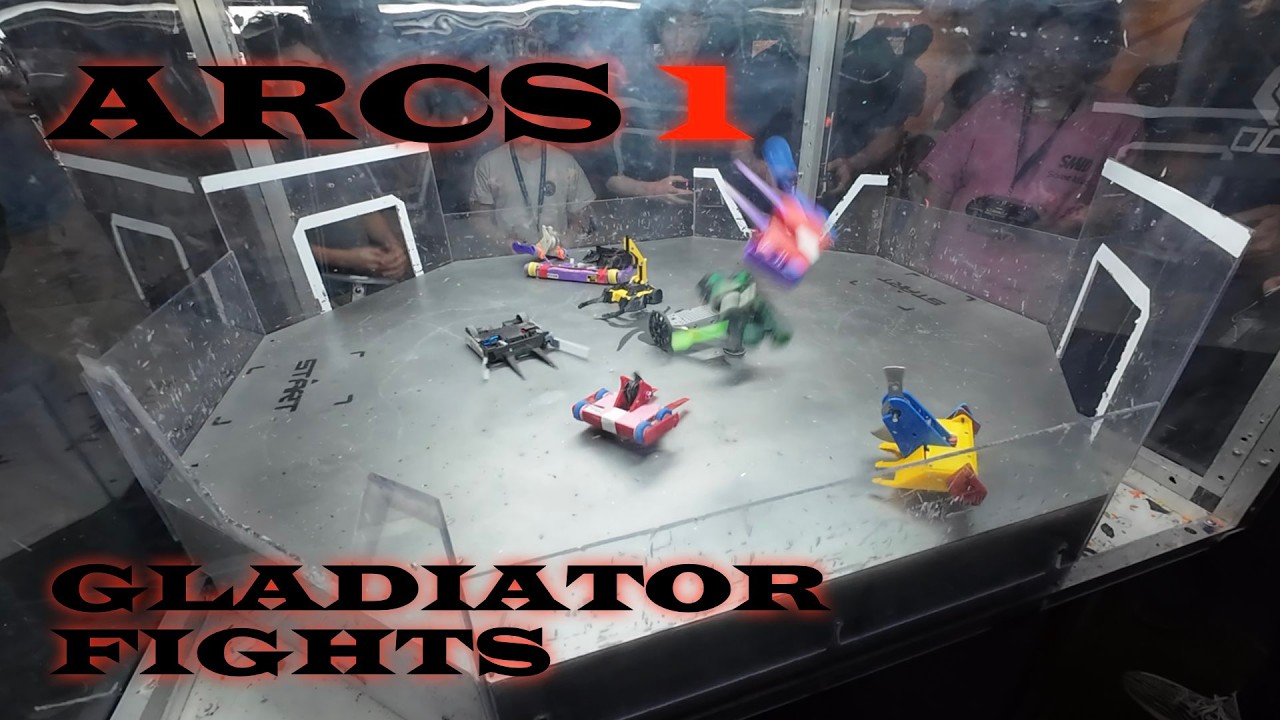
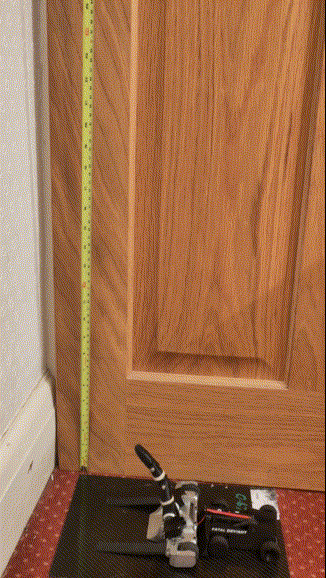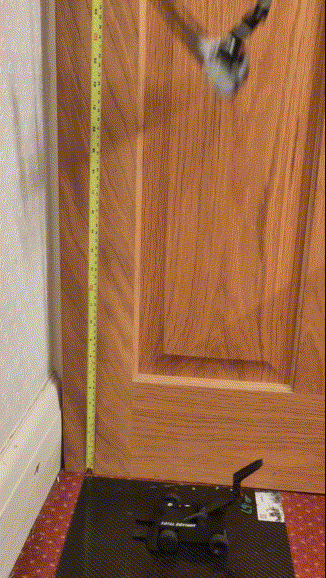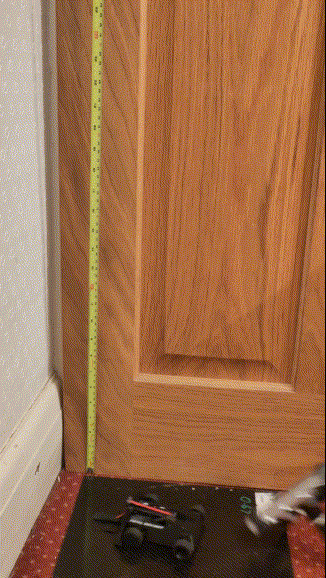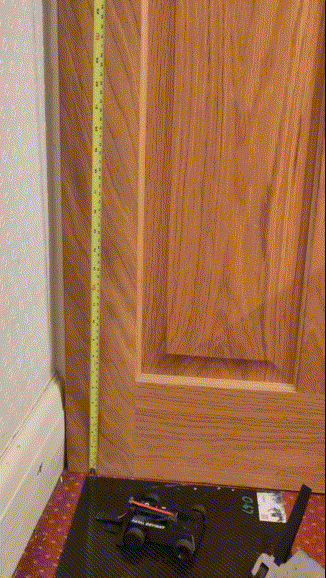
I’ve realised my end goal here is the “acoustic roof shot”, ie one not requiring a spinner. I’m already pretty close - I flipped Expandabot in the first ten seconds of the fight and it very nearly hit the roof! The GROCS arena is about 600mm tall from floor to ceiling, so there’s some events that would already have been a roof shot at. I measured a couple of flips at home (on a slightly underweight robot, 120g or so) at almost 600mm, so fingers crossed I think I’m only a few tweaks and efficiency improvements away from That Flip.
Thank you for reading about my longest running un-documented robot. I really enjoy how quickly and cheaply antweights allow me to iterate my own silly designs to do silly things. Maybe I’ll filter some improvements back to Fatal Deviation considering its current sorry state?