AWS has changed their rules so that weapon locks must not be taken off in a way that requires touch the robot. However, my new vert has separate configurations which change the weapon’s shape. One is a disc with 3 hollow areas, and the other is a bar with no hollow areas. Both are 60mm. How can I design or find a weapon lock that works for both?
same way as you would for the disc. the locking bar should be positioned in a way that it can stop the rotation of either config, so go through the holes of your disc or slots past the bar and stops the bar as it rotates.
Would a clip positioned on one of the teeth of the weapon be legal? It would stop the robot from spinning up.
we wouldnt allow any friction based lock. the locking bar should actively stop the rotation
3 Likes
The problem is that my antweight looks a bit like this. Where would I put the lock (and not on the spoiler as this is an old image)? Am I allowed to use a tool to remove it?
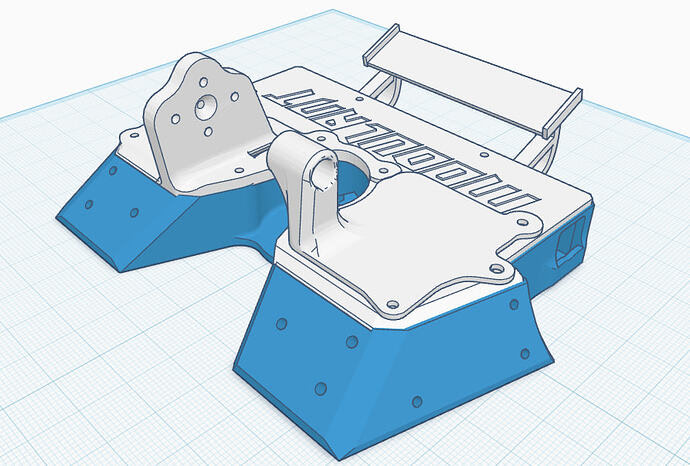
You could design in a small hole into the main weapon mount, such that you could insert a screwdriver or long rod through it, stopping the weapon from spinning. Bonus points if the weapon mount is TPU, which combines to grip the weapon lock, stopping it from falling out
my bot, for reference:
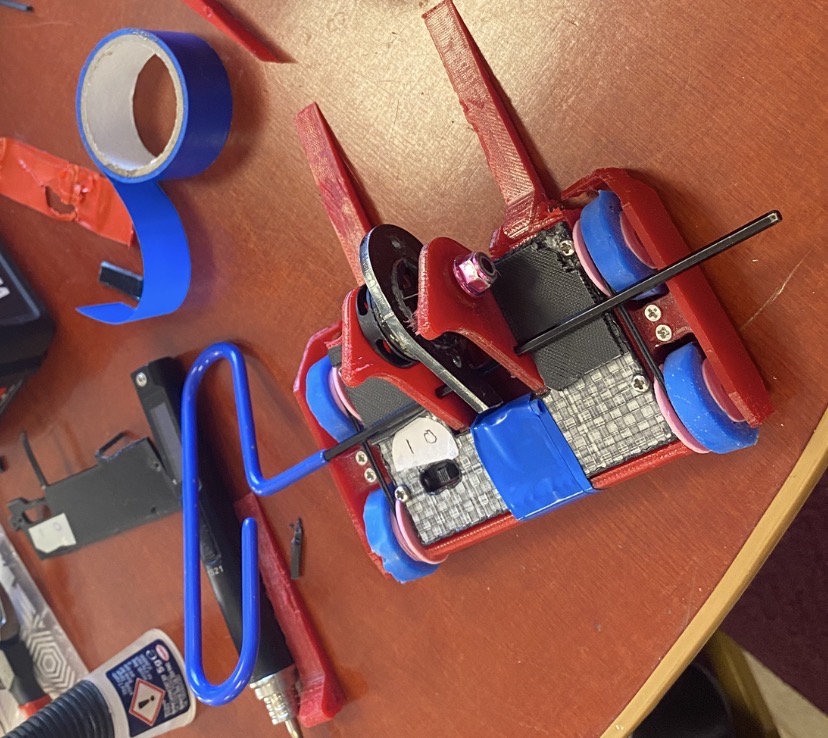
You don’t need both sides to be supported, just for there to not be enough play for the weapon to get close to spinning
5 Likes
Wouldn’t you need to touch part of the antweight to remove the lock though? Would that make it illegal?
Assuming the weapon lock is large enough, you can grab that before grabbing the main robot, and pull it away, stopping you from needing to touch the robot
I asked Ben about friction fit through a bulkhead (because currently I do it the same way as you) and he said no - too much potential for slop, misalignment etc that means either it falls out if you drop the robot or the robot drives itself off the table because you left it switched on and went to go fight a different robot (which has happened on a table next to me, I had to unceremoniously jam a screwdriver in the weapon assembly before I was sure it was safe to switch off), or you have to pick the robot up and wrestle it in.
I agree with him - while mine is toleranced pretty well at the beginning of an event and doesn’t fall out, I still have to put a finger on the robot to get it in and out, and there’s no way I can guarantee it’ll be just as well toleranced (or aligned) at the end of an event. Also, if it’s going through PLA parts and you’re leaving the robot on the shelf for a period of time with the locking bar in, you’ll find that the plastic creeps to conform to the locking bar and it will get looser over time.
You should be able to easily insert and remove the main locking element (pin, screw etc) without touching the robot with the other hand (giving the weapon a little prod with the locking bar to rotate it to where you can insert it is fine). The locking bar should then have a secondary retaining element attached like a wing nut (you can touch the robot to do this now that there’s something blocking the rotation of the weapon) so that you can pick up the robot and shake it, or drop it on the floor, without the locking bar falling out.
I’m planning on putting a hole in the bunny ears above the weapon that allow me to put some threaded rod through with a wing nut on each end:
Some other options include:
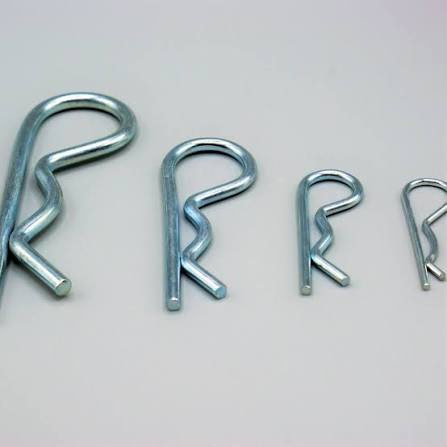
- A plain rod cross-drilled for an R clip*, I’d recommend tying the clip to the locking bar with some string so it doesn’t get lost and is easier to remove.
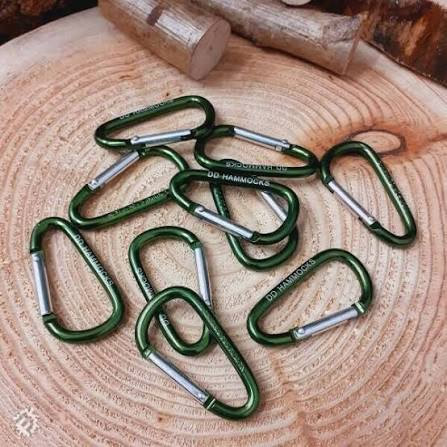
- A bolt, carabiner** etc through a hole in the weapon.
- Some kind of prongy forky thing that goes between the weapon axle and the body of the robot, either side of the weapon blade, and has some kind of clip or fastener on the other end - R clips, threaded hole for a screw etc.
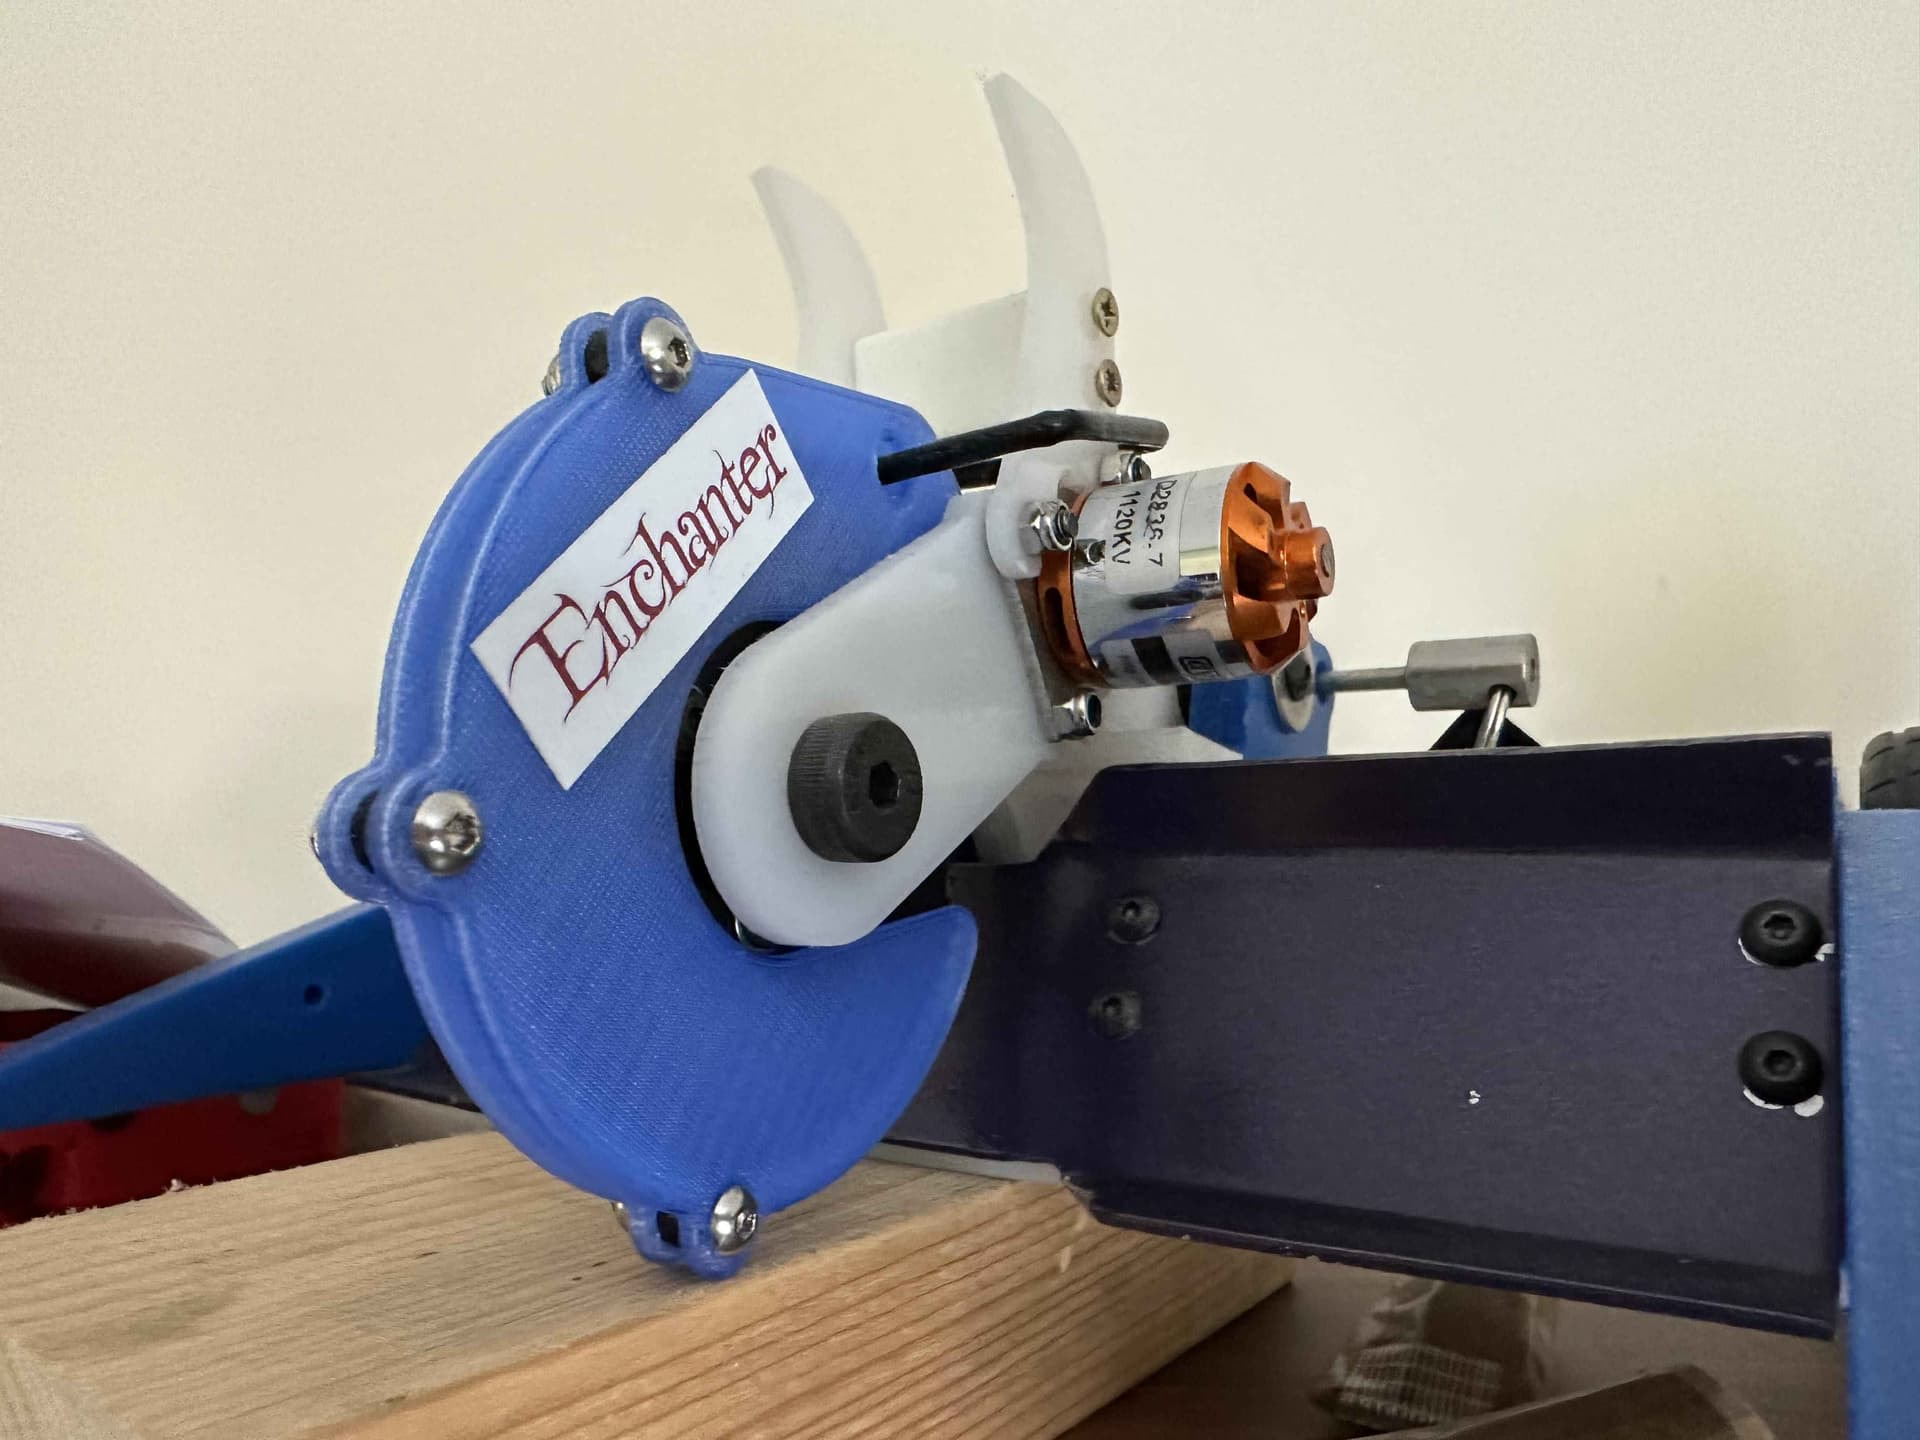
- A folding clamshell*** around the weapon disc (like you see on hammersaws as combined weapon lock/sharp edge protection).
- A captive nut in the bulkhead or chassis that you can screw a long bolt into.
*R clip: (note I have a lifetime supply of these I bought about 20 years ago (gosh) as RC car body clips, so if anyone needs a couple let me know)
**Mini carabiner:
***Clamshell: (this one is from Craig’s weapon lock thread)
I hope that helps clear things up! There are some sketchy locking setups out there and while it’s a little inconvenient to implement something with positive retention, losing a couple of fingers is far more inconvenient.
1 Like
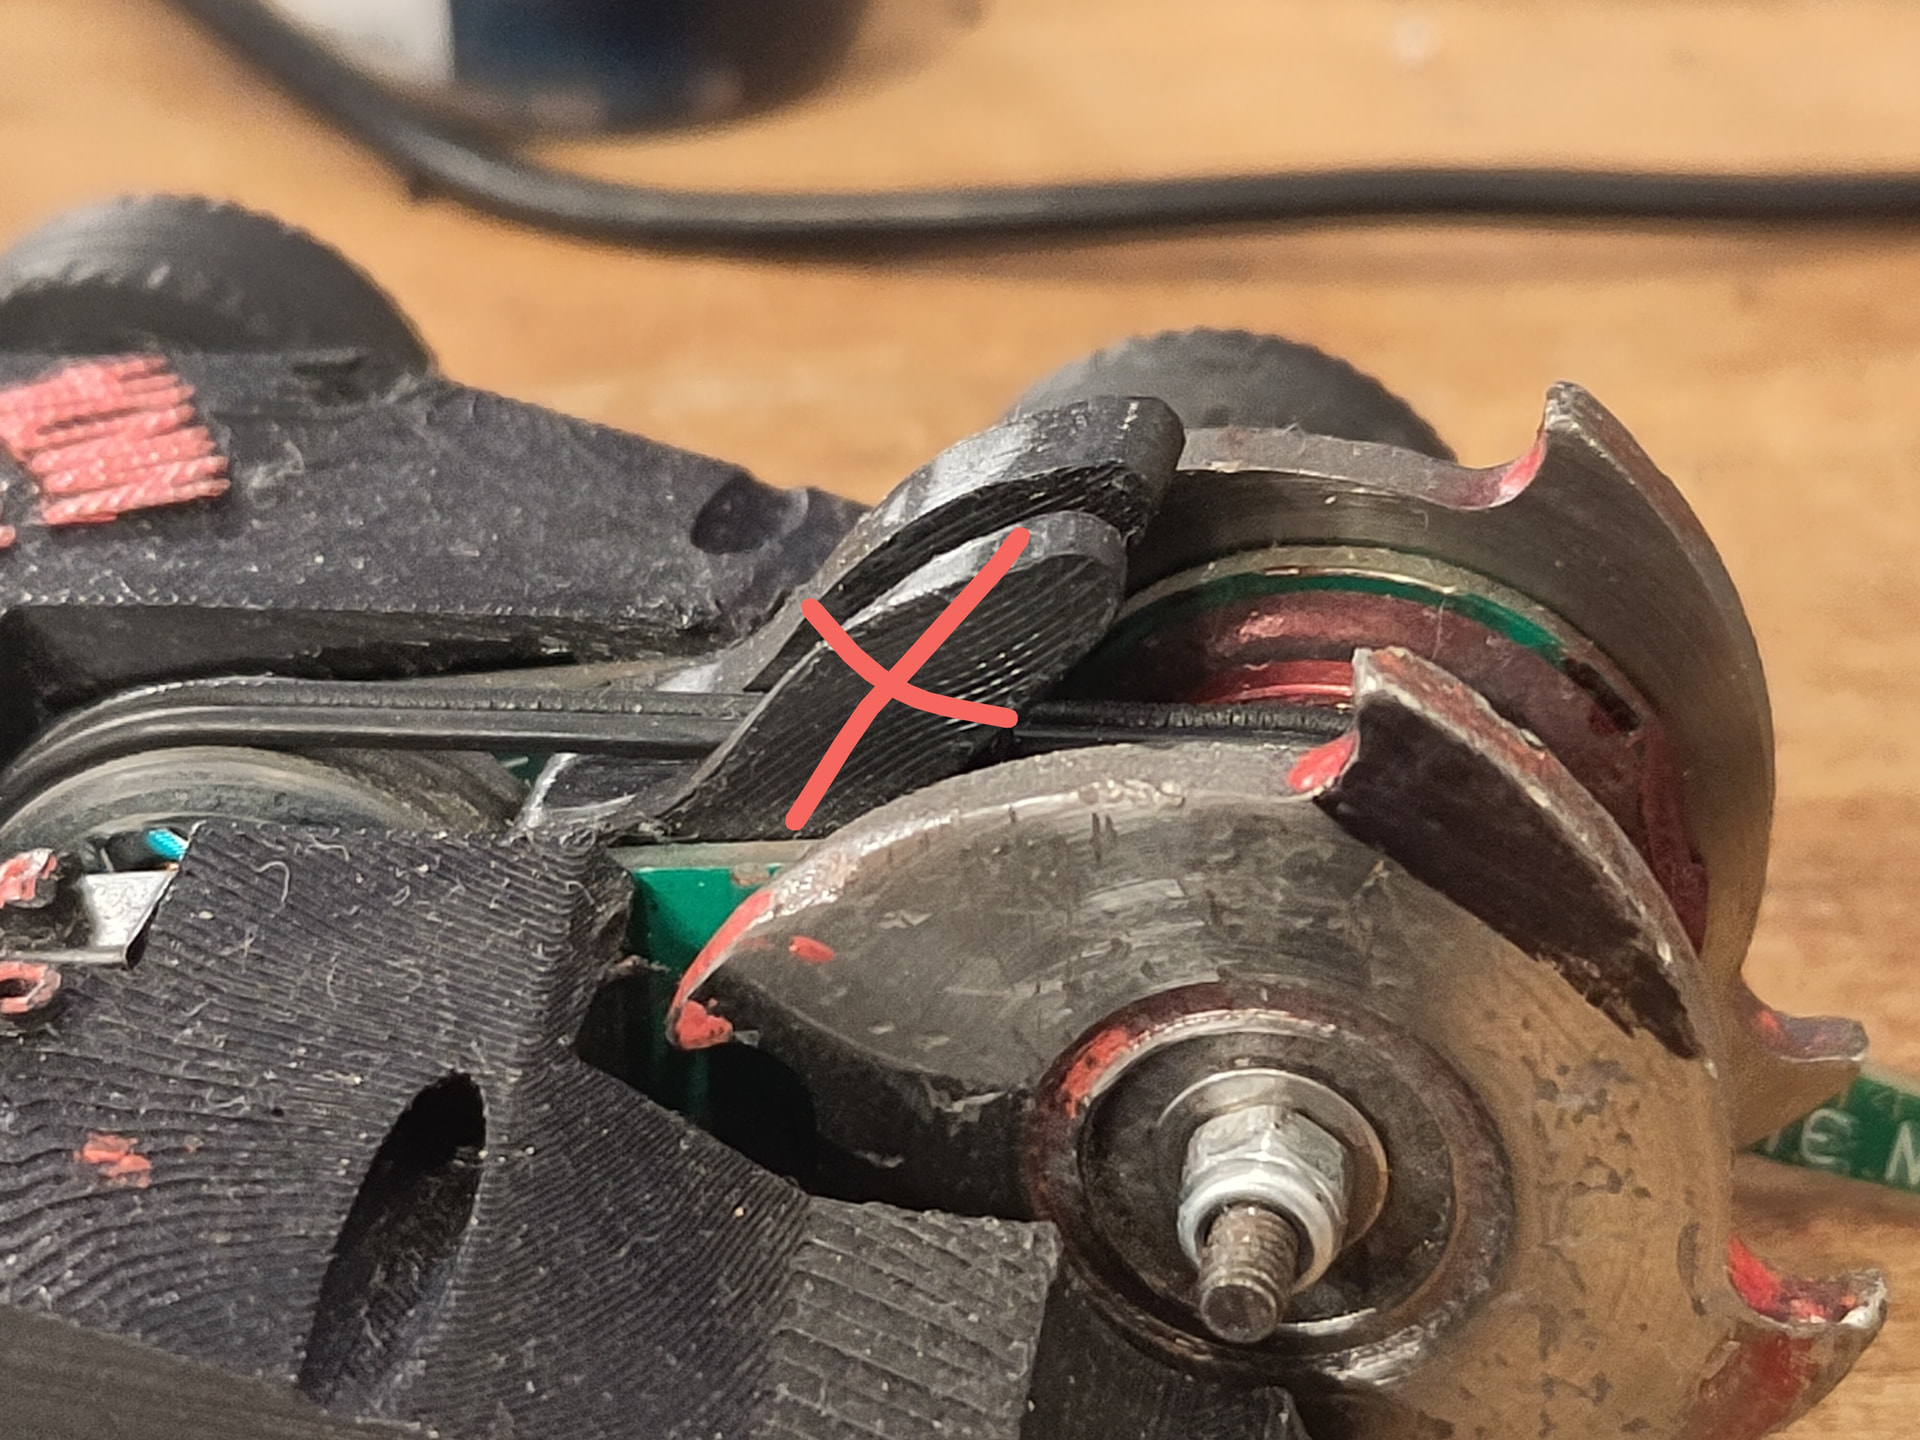
I was thinking about the carabiner clip for the disc, but there’s nothing I can think of for the bar which doesn’t require changing the design.
Do you have a picture? I’m sure one of my suggestions could be adapted to suit.
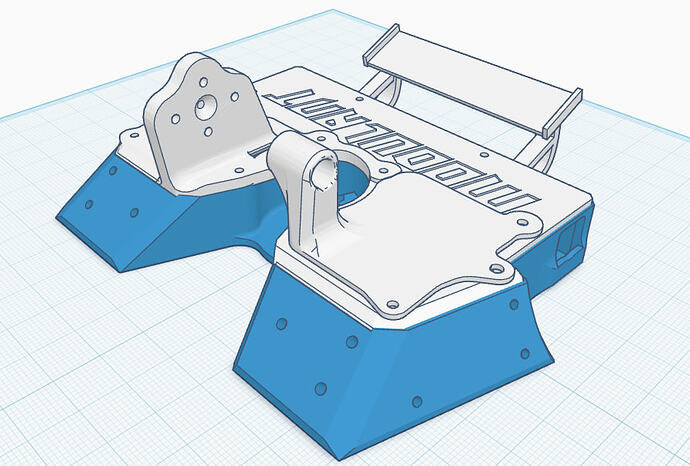
I mean with the blade attached, sorry!
Would something that lodges in the hole between the spinner and the chassis be allowed?
As long as it stops the blade spinning, you can insert it with only one hand, and there’s some kind of clip or screw that stops it falling out if you turn the robot upside down, yes! I’m imagining some kind of T shape piece that slots through the gap, then you put a bolt into the bottom of the T to stop it from pulling back out again.
2 Likes
Thanks for some great replies here Joe, spot on..
Yea Edwin, if you can slide a wedge in (locking the weapon) and then lock that wedge inplace once the robot is made safe (for example an R clip or carabiner) through the end under the robot, then that’s acceptable.
A carabiner through the weapon preventing 1 full rotation is also acceptable.
you could use both, and swap depending on weapon choice at the time.
Id recomend battery removal during weapon swap as you’ll probably both want to charge it anyways, and it makes it safe for lock removal on the bench.
1 Like
As discussed by Joe, this is currently not really acceptable (it’s close and pretty good).
if the pin slides in easily and is then retained on the end so it can’t all out then we’re good!
a groove on the tool with an R clip, or a threaded tool with a nut (or even better a wingnut) would be good.
tbh the retaining feature on the end of the lock could be friction fit, but would have to be strong enough to lift the robot by friction alone (so more than say 225g of retention force worse case), and not be part of the robot (so it’s easy to slide the lock in place, and then add retaining feature)
As I can’t easily measure 225g of pull at check in I’d rather not have to do that! 
2 Likes
Would it be legal to use a tool to remove the lock?
Ideally it should need no tools to removing or inserting, however a tool to put the 2nd retaining feature on would be ok.
what did you have in mind?
I can always see what you’re trying to do and see how we can make it work for you..